mirror of
https://github.com/Kpa-clawbot/meshcore-analyzer.git
synced 2026-11-22 08:47:04 +00:00
 ZachandClaude Opus 5.5
1a6322a707
Closes #2428.

Adds free and open map providers (topographic, satellite, gray and
vector basemaps), a hillshade overlay, and support for operators' own
tile servers. Everything is additive and opt-in: Carto stays the
default, every new provider group is off until the operator turns it on,
and no existing config key or provider was removed. An upgrade with an
untouched config changes nothing in the picker.

> **Dependency:** #2426 has merged. The branch is rebased onto current
`master` (`6c78a1d2`) with no conflicts.

## What's new

- **Provider registry** (`public/map-tile-providers.js`). New groups are
**opt-in**: each is off until `map.tiles.providers.<group>.enabled` is
`true` (the boolean), so licences and volunteer servers are the
operator's call:
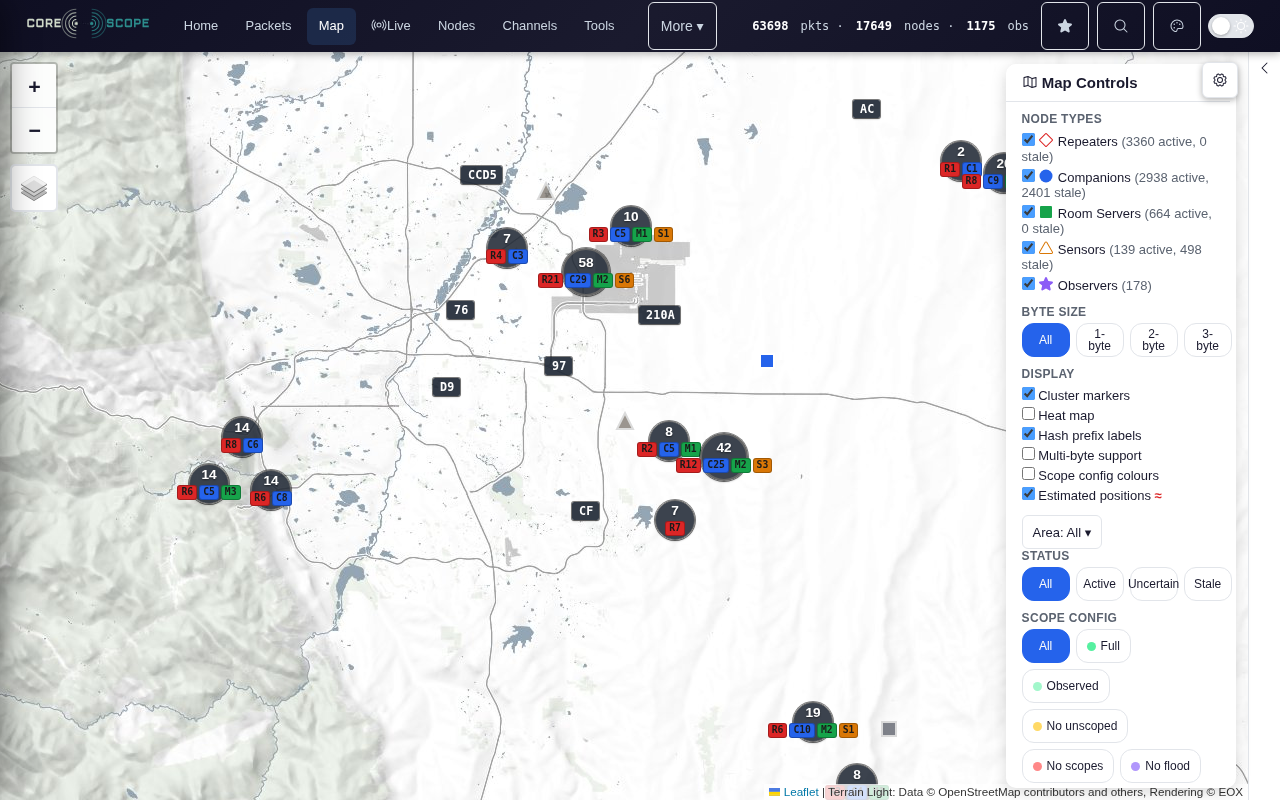
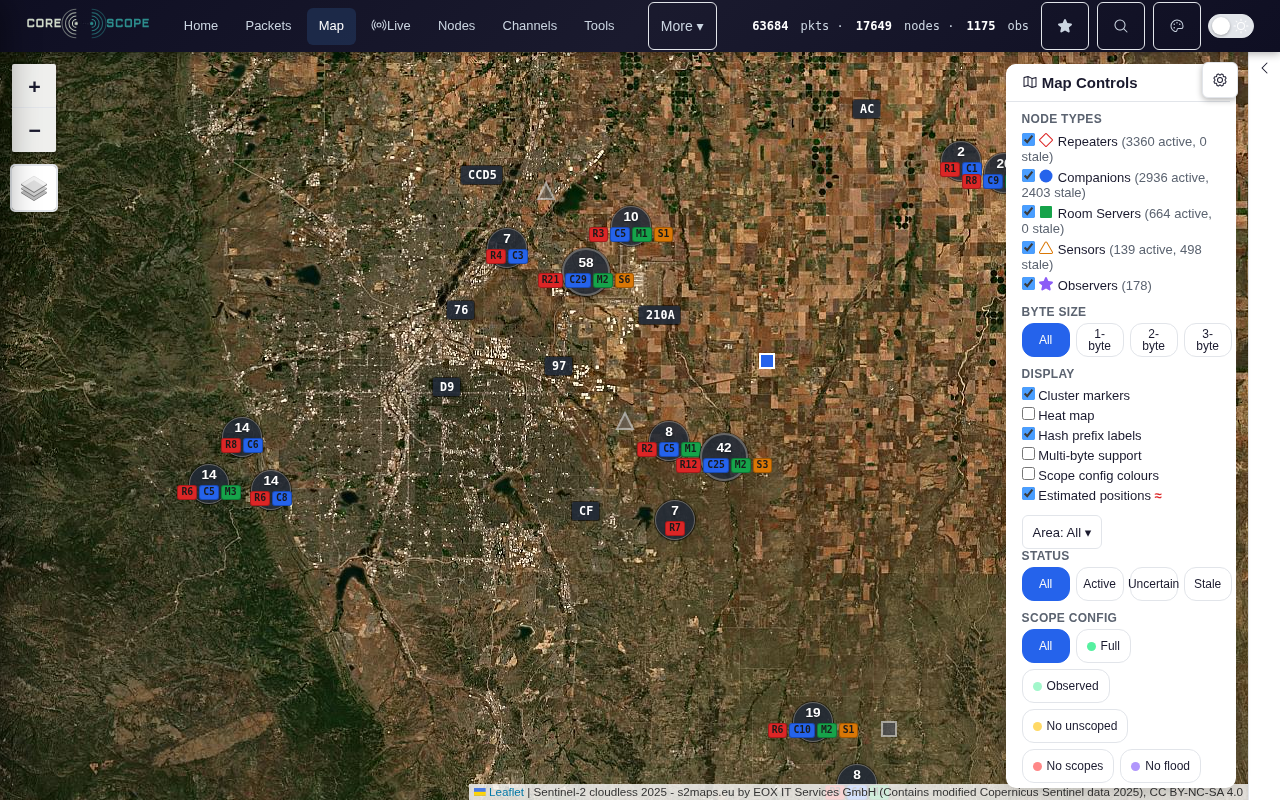
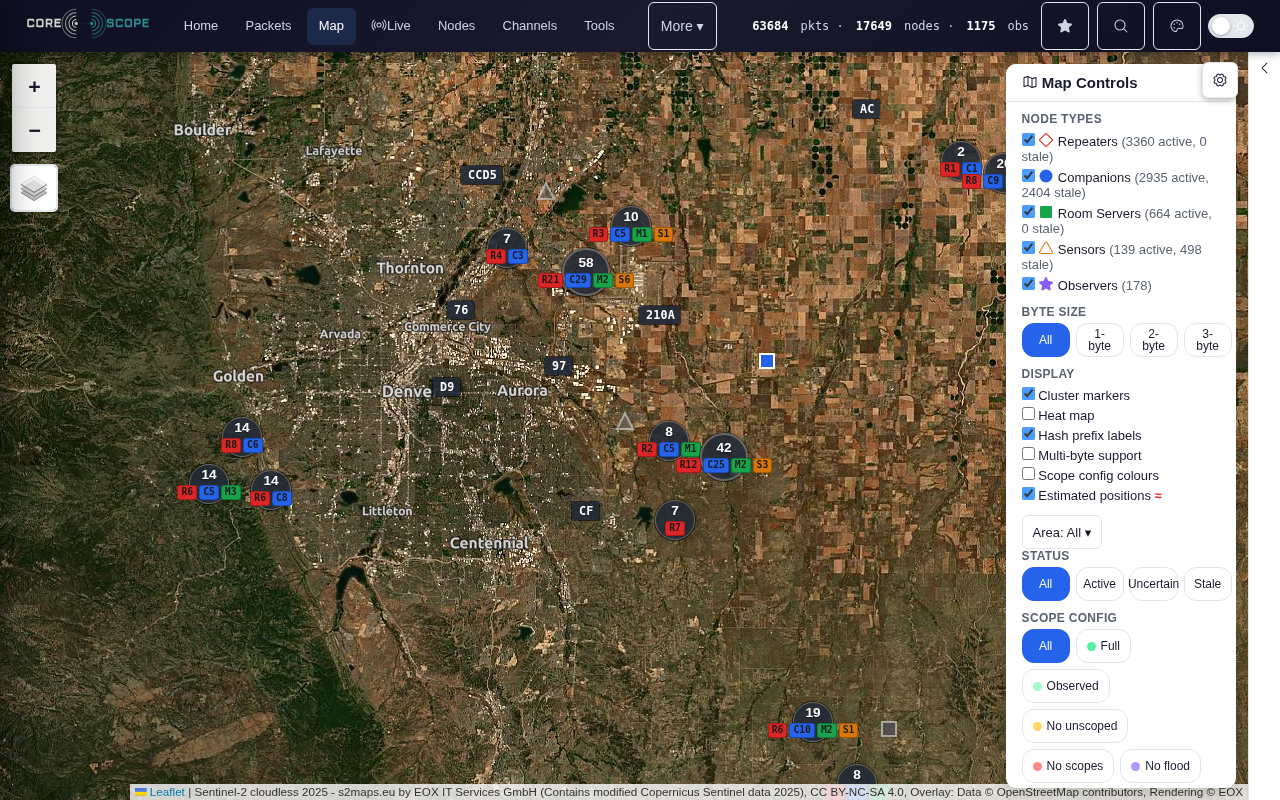
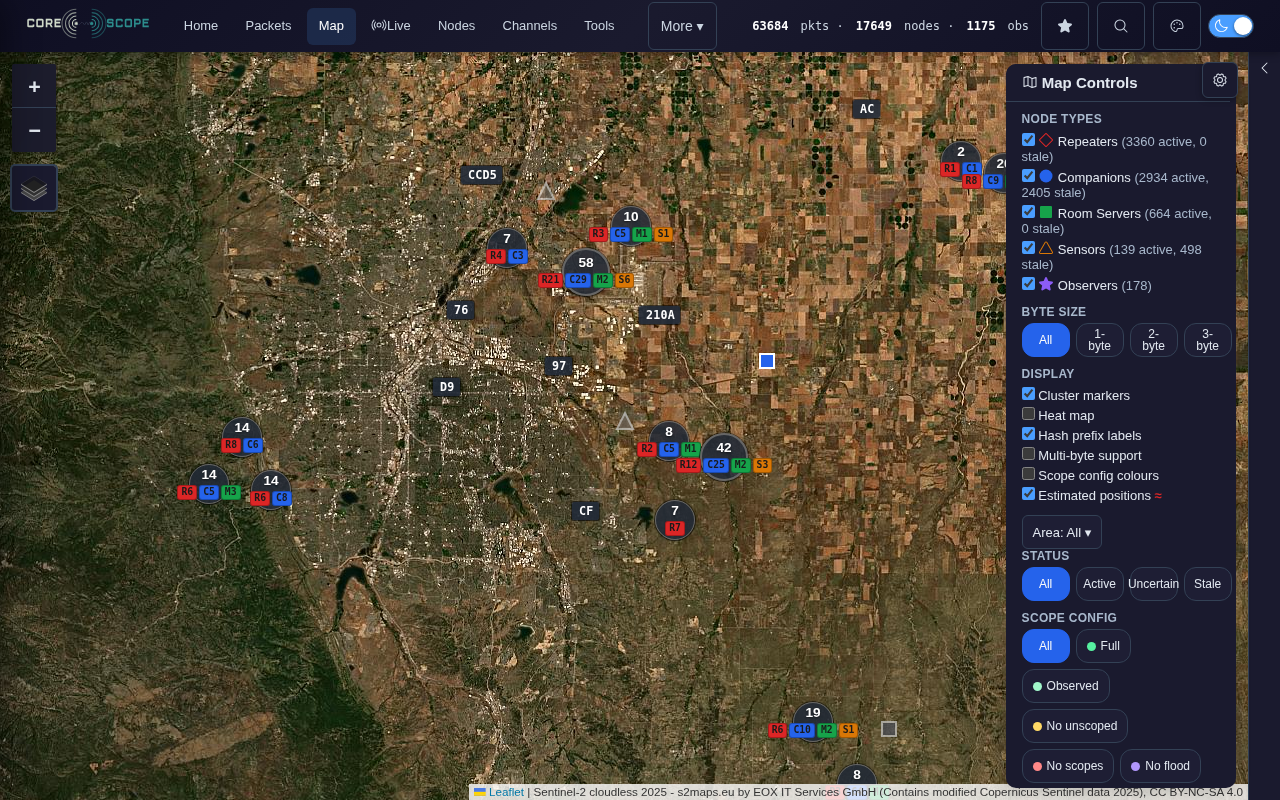
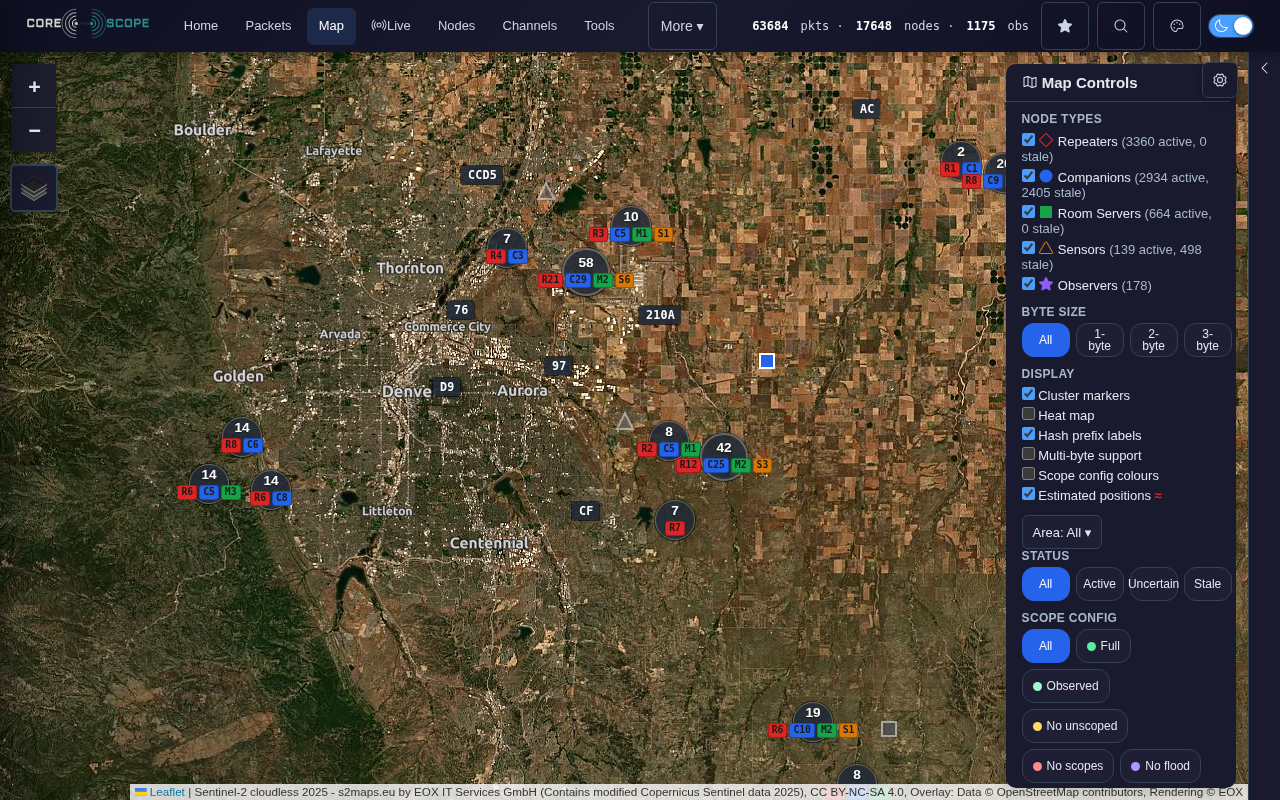
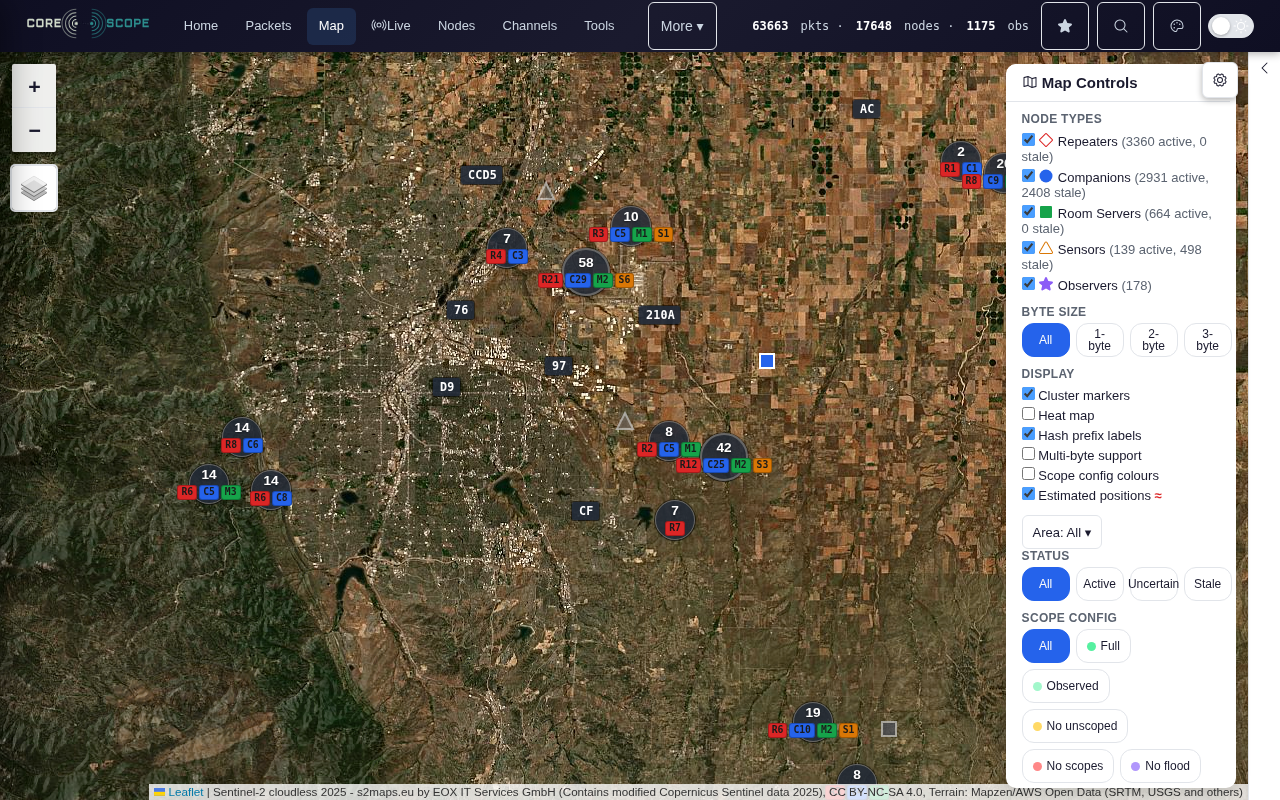
- **EOX**: Sentinel-2 satellite (2025 and 2016), Terrain Light, and a
place-labels overlay. EOX 2025 imagery is CC BY-NC-SA 4.0
(non-commercial); a commercial deployment should leave `eox` off or
license it.
- **OSM France**: Humanitarian, CyclOSM, OSM Gray and OSM Gray Dark
(volunteer-run, fair use).
- **OpenFreeMap** and **VersaTiles** vector styles: Liberty, Bright,
Positron, Dark, Fiord, Colorful, Muted and the Gray variants.
- **Hillshade** (below) is opt-in the same way. **OpenTopoMap**, the OSM
community server, Stamen and USGS keep their existing opt-in.
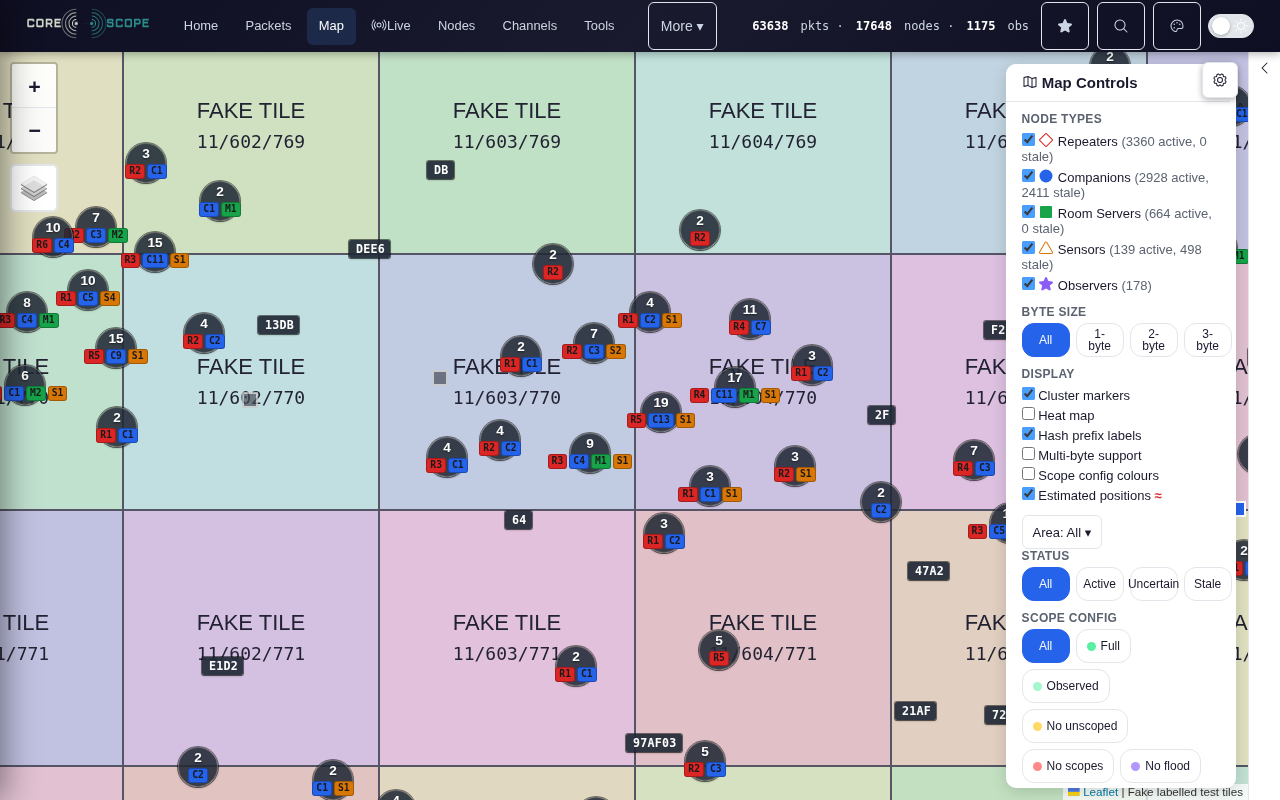
- **Custom tile servers**: `map.tiles.custom` adds raster (XYZ), vector
(MapLibre style URL) and raster-overlay entries as `custom-<id>`. They
can be used in `darkDefault` / `lightDefault`. Invalid entries are
skipped with a console warning.
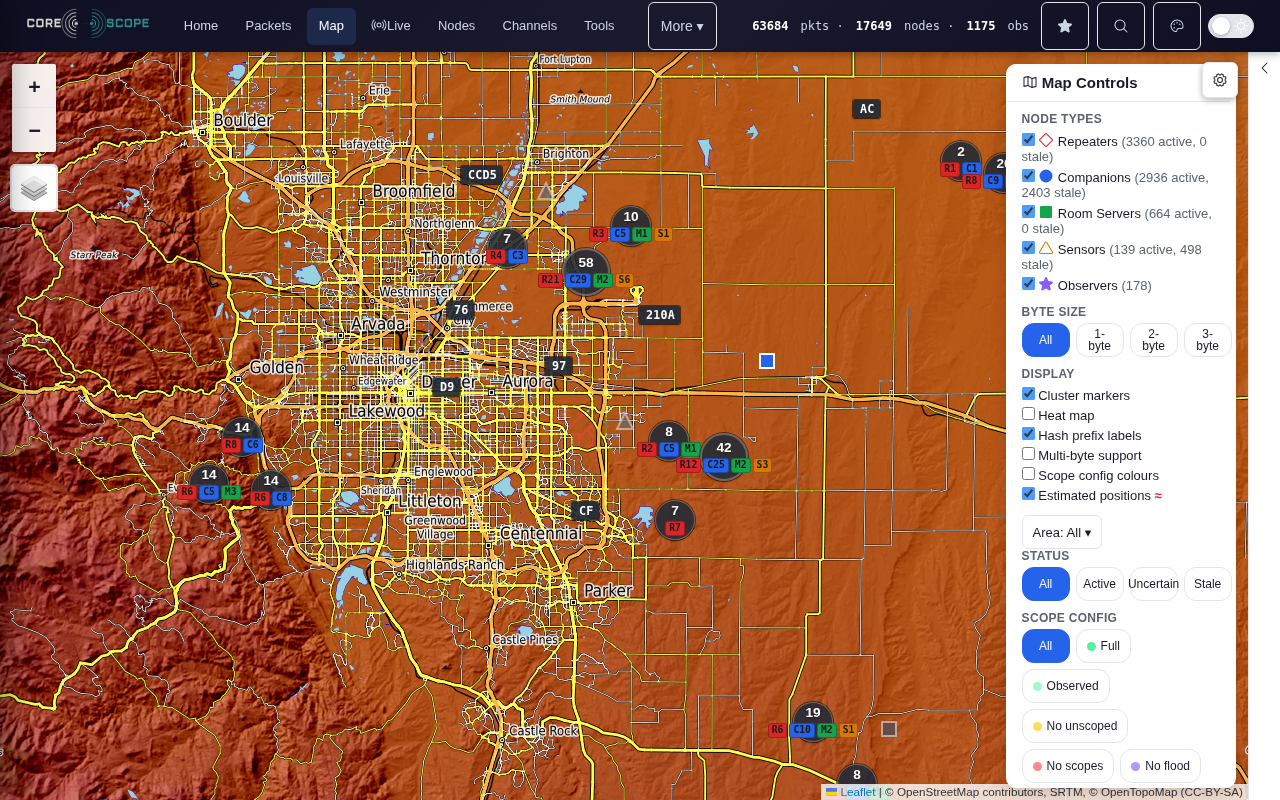
- **Hillshade overlay** (`public/map-hillshade.js`): shaded in the
browser from Terrarium elevation tiles.
`map.tiles.providers.hillshade.url` can point at a mirror.
- **Vector basemaps** (`public/map-vector.js`) use a vendored MapLibre
GL 5.24.0 (CSP build) and `@maplibre/maplibre-gl-leaflet` 0.1.4.
- They are lazy-loaded only when a vector map is picked (about 380 KB
gzipped).
  - The load times out after 15 s.
  - Without WebGL the map falls back to the theme's default raster map.
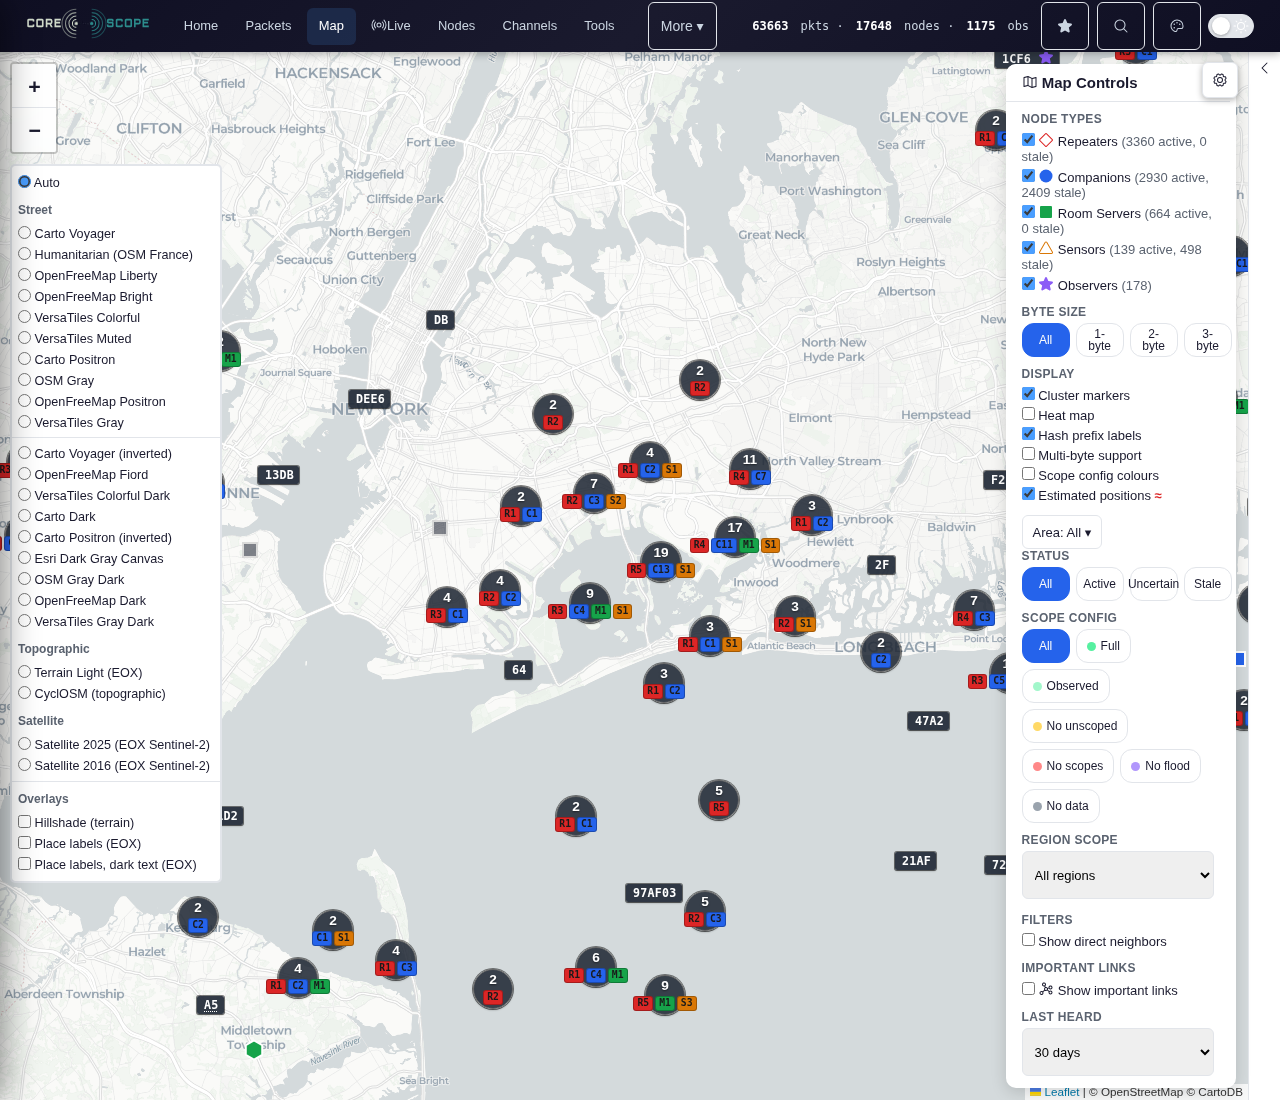
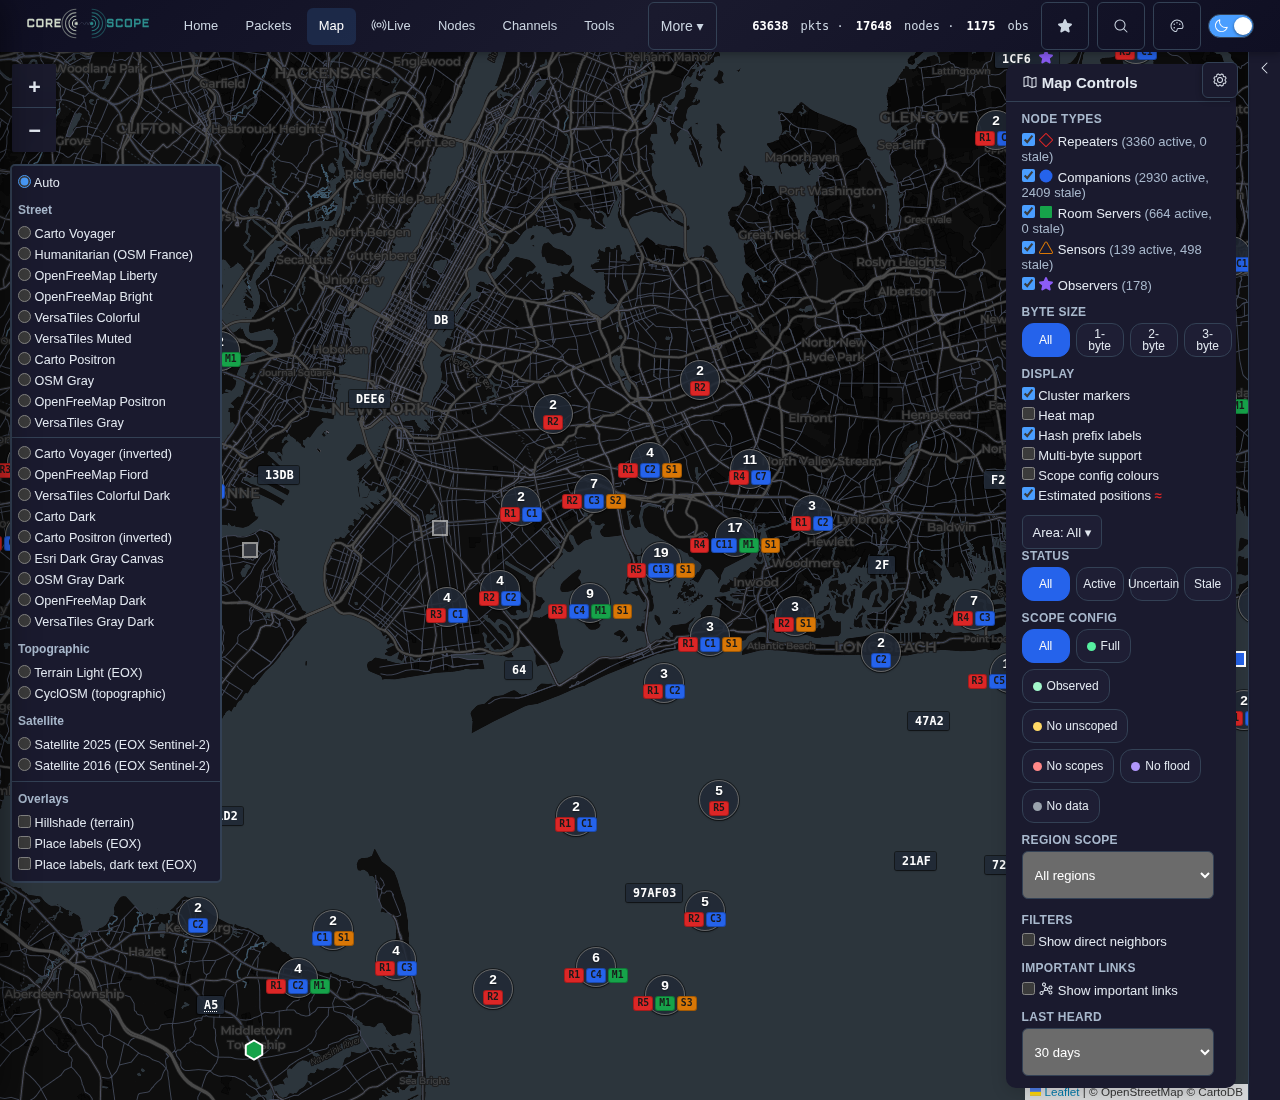
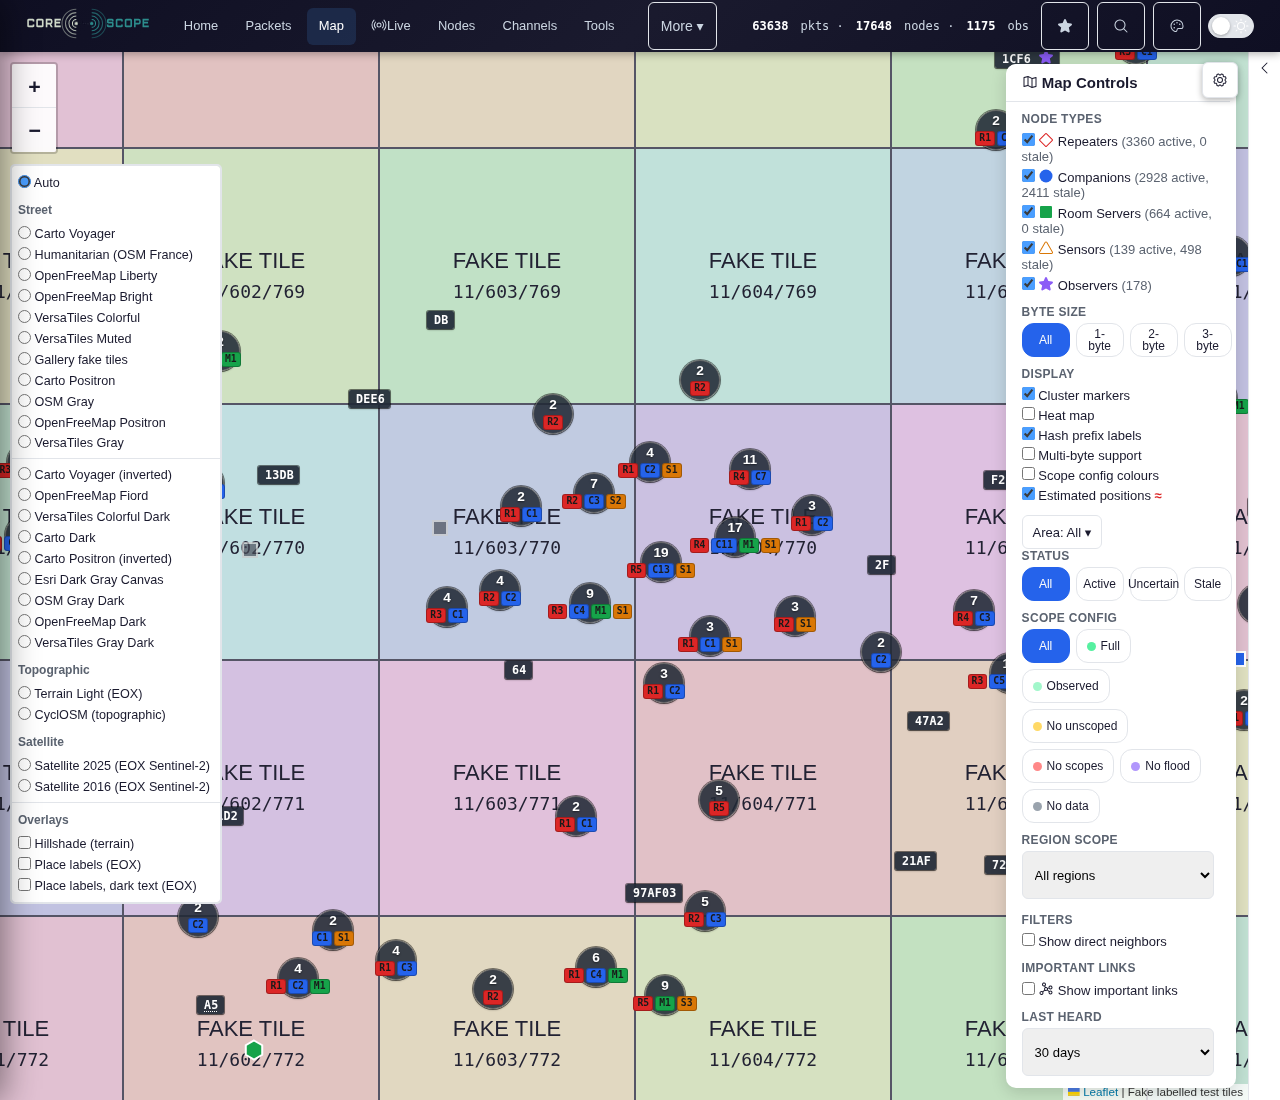
- **One picker on Map, Live and Repeater Planner**: Auto, Street,
Topographic, Satellite, plus an Overlays group.
- **A map picked there is saved** (`localStorage` `mc-tile-pinned`,
untrusted: honoured only while registered). Every picker reopens on it
after a reload or on another page, until the visitor picks **Auto**.
- The other maps (home mini-map, node detail, node reach, analytics)
follow the visitor's choice through the shared builder: the saved pick
when it suits the current theme (satellite always does), otherwise the
theme's map.
- Those small maps never load MapLibre, so a vector choice shows the
theme's default raster map there.
- **Security contract**: the `CONTRACT` block at the top of
`map-tile-providers.js` (S1 to S7) covers one shared tile-URL validator
(`https?://` or a same-origin path, no credentials in the authority,
whitelisted placeholders), attribution HTML-escaped once, picker labels
set with `textContent`, explicit MapLibre options, pinned vendored
versions, CORS-safe hillshade decoding, and treating stored picks as
untrusted input. `map.tiles` is served publicly in `/api/config/client`,
so keys put there are public (the docs warn about this).

## Fixes included

The race stress suite written for this PR found teardown races when
leaving map pages mid-load:
- a lazy MapLibre load finishing after navigation;
- a hillshade tile decoding after `remove()`;
- a provider-change event arriving during teardown.

It also found a pre-existing document-listener leak in `AreaFilter` /
`RegionFilter`. All of these are fixed in `e6709e74`, with regression
tests in `tests/e2e/test-map-teardown-races.js`.

The first CI run then caught a bug in that fix (`7f8d792c`).
`MC_safeRemoveMap` called `map.off()` before `map.remove()`, so the
map's `unload` event reached no one. Leaflet relies on that event to
detach controls and clean up the zoom-animation proxy and BoxZoom, and
`test-issue-1206` watches it to confirm node maps are disposed. `off()`
now runs after `remove()`, and a new regression test checks that
`unload` fires, controls detach and no listener is left.

A later stress run (a new seed) found a real two-tab bug, fixed in
`0506fc1d`. When another tab's overlay pick is already in localStorage
but its `storage` event hasn't arrived, a layer-picker click here
triggered a sync that added that overlay while Leaflet was still
applying the click. Leaflet doesn't redraw the list for changes it sees
mid-click, so the overlay's checkbox stayed unticked, and the next click
on any overlay removed it and wrote the removal back to every tab. The
overlay set now defers a sync until the click has finished. New E2E
check `4b` in `test-map-providers-e2e.js` plants another tab's pick and
clicks twice: one write per click, the planted overlay stays ticked. It
fails on the previous code.

## Docs

- `docs/deployment.md`, "Map Tile Providers" section, rewritten. It
covers every provider and its licence, turning groups on and off, custom
servers, vector maps, hillshade, self-hosting, and what is public.
- User guide:
  - `map.md` gets a "Map style and overlays" section;
  - `live.md` notes the picker;
  - `configuration.md` gets a "Map tiles" section;
  - the FAQ gets a new entry on satellite, terrain and gray maps.
- `CHANGELOG.md`: an Unreleased entry.

## Test data

Two datasets were used, so every number below says which one it came
from.

**1. Large synthetic dataset** (perf A/B and screenshots). It is
generated, contains no real mesh data, and is not checked in.

- **Generator:** `synthgen` 1.0.0, seed 1, "full" scale. Built from
upstream `be16173e` and retimed so its 18-day window (2026-10-31 to
2026-11-18) ends at the time of the run.
- **Database:** SQLite, 3.94 GB (586 MB as zstd), 11.6 M rows in all.

| Table | Rows |
|---|---|
| Nodes | 18,102 (12,606 companions, 3,652 repeaters, 953 rooms, 891
sensors) |
| Nodes with a location | 13,452, spread worldwide (latitude −37° to
60°, longitude −123° to 175°) |
| Observers | 1,175, in 42 regions on six continents |
| Transmissions | 759,133 |
| Observations | 10,569,668 |
| Neighbour edges | 42,806 |
| Advert route evidence | 212,142 |

During the perf runs, the server's packet store was pinned to the newest
48 h with a 1.5 GB memory cap. Each server held about 65 k transmissions
and 0.9 M observations in memory (baseline 65,647 / 906,467; candidate
64,862 / 896,248), plus all 18,102 nodes (about 17,650 active) and 1,175
observers. The tracked store was about 450 MB.

**2. The repo's CI fixture** (`test-fixtures/e2e-fixture.db`, 704 KB).
All E2E suites and the race stress gates ran against it, freshened the
way CI does: 204 nodes, 31 observers, 500 transmissions, 502
observations. A second copy with the Repeater Planner enabled was used
for the planner-on stress runs.

**Perf environment:**
- Headless Chromium 158 via Playwright 1.58.2, at 1280×800 with device
scale factor 1.
- 9 measured runs per scenario plus 1 warm-up, on each of `master` and
this branch.
- Host: Linux, AMD Ryzen 7 3700X (16 threads), 63 GB RAM.
- **Tiles were stubbed.** The harness answers every tile, elevation and
style request locally with the same stub on both sides (`--mode stub`),
so perf timings involve no network. Only the screenshot gallery uses
real tiles.

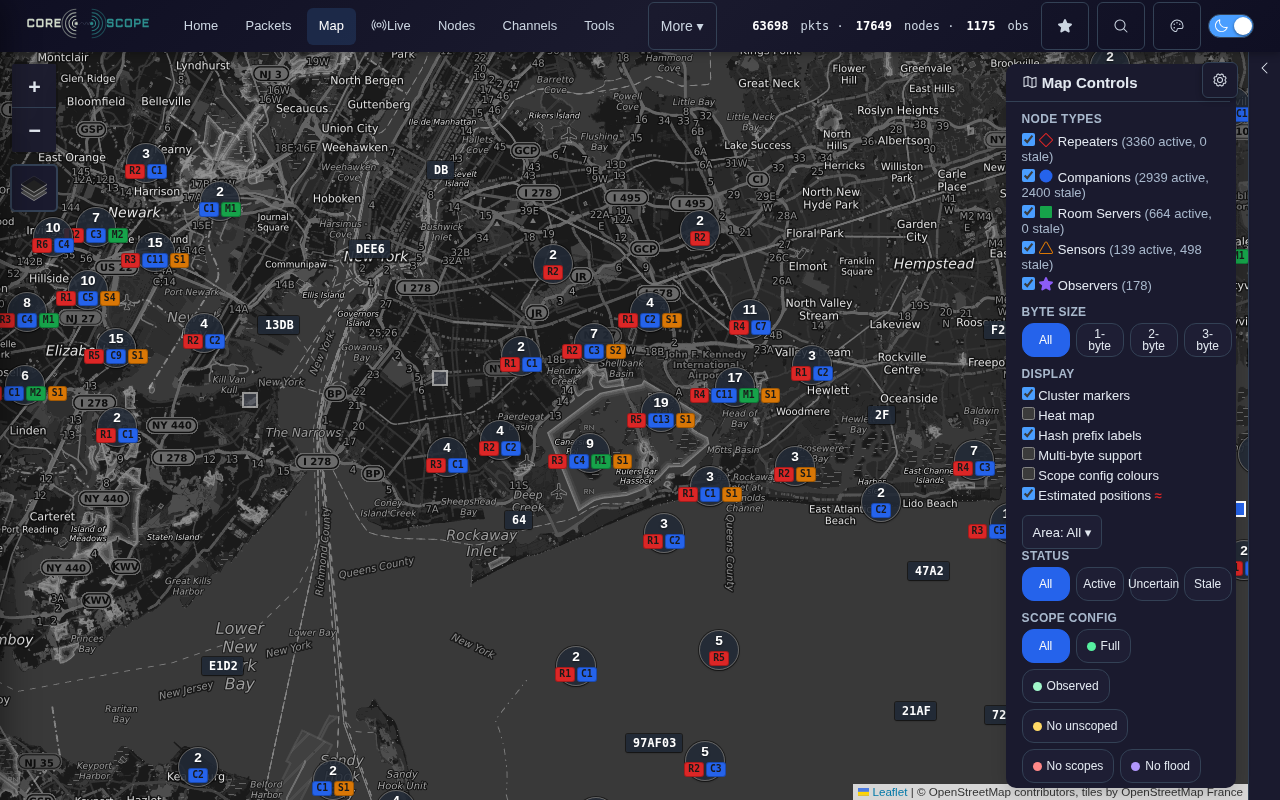
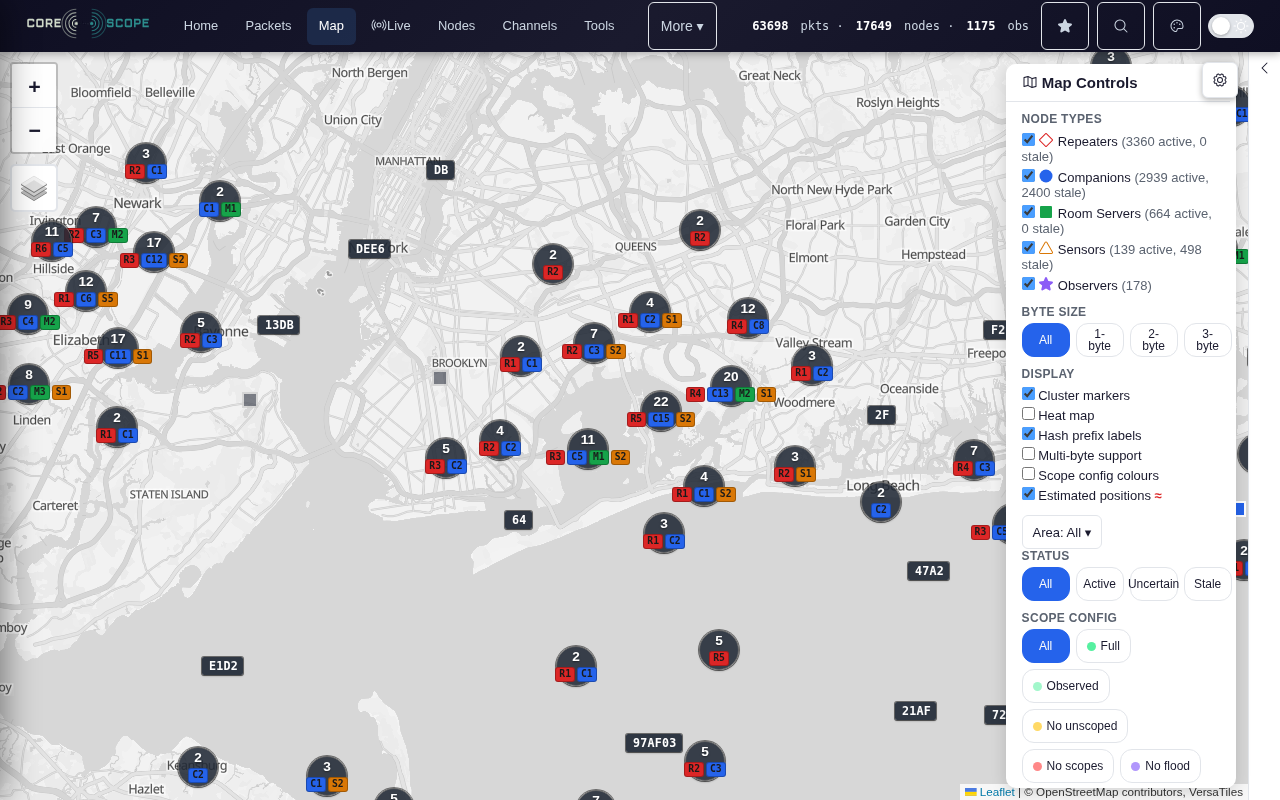
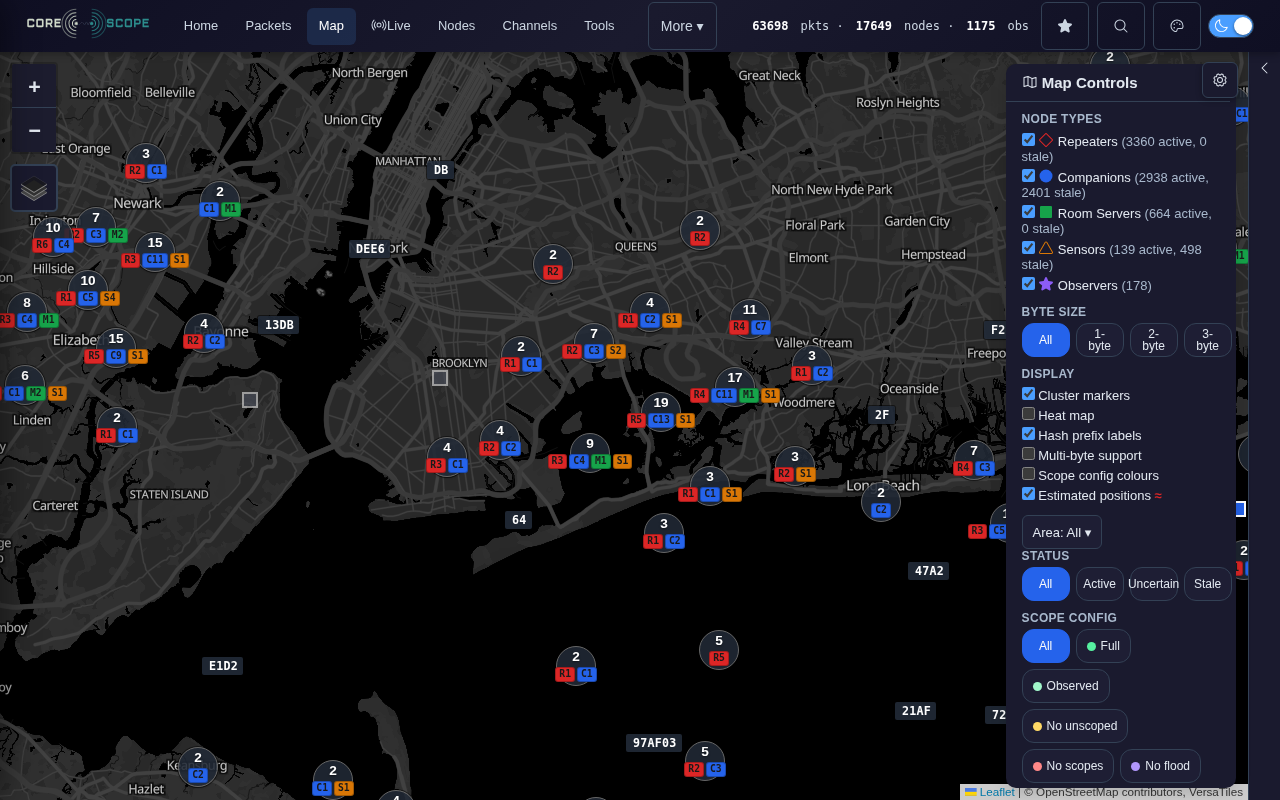
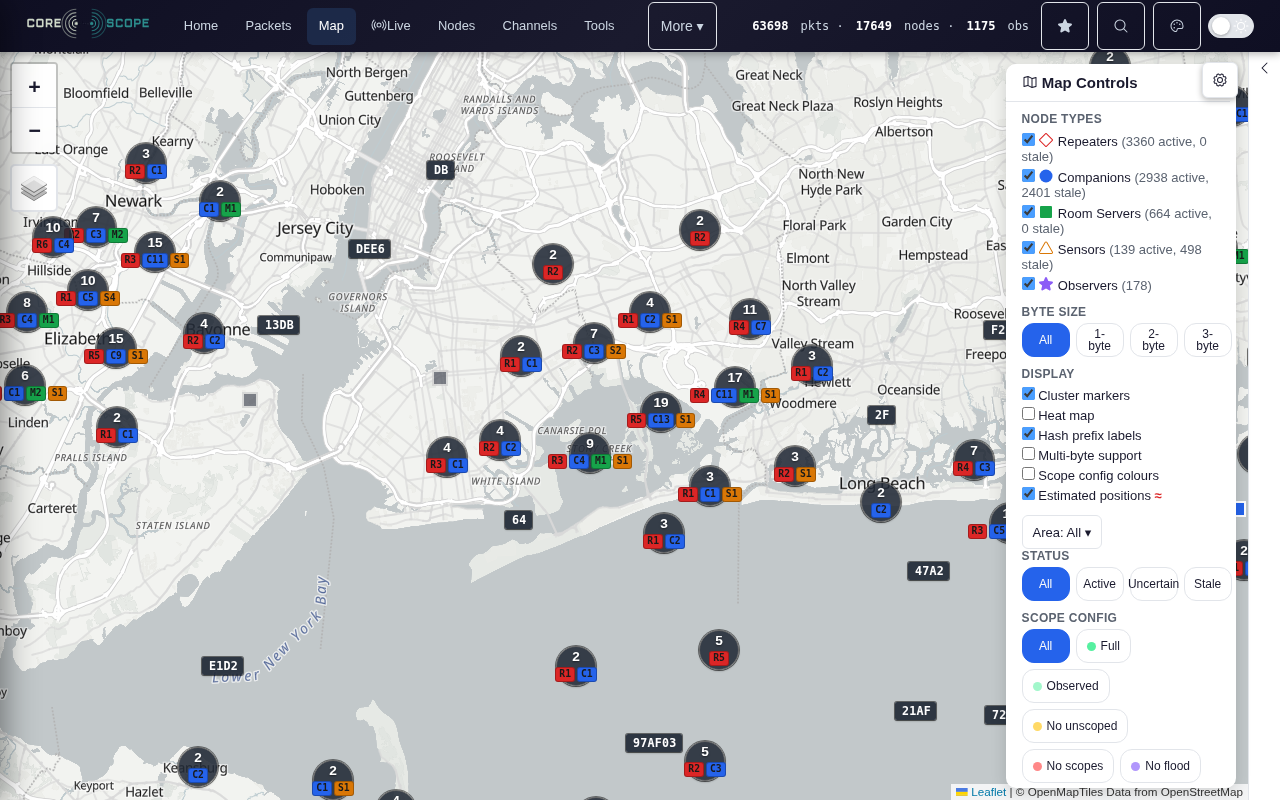
## Screenshots

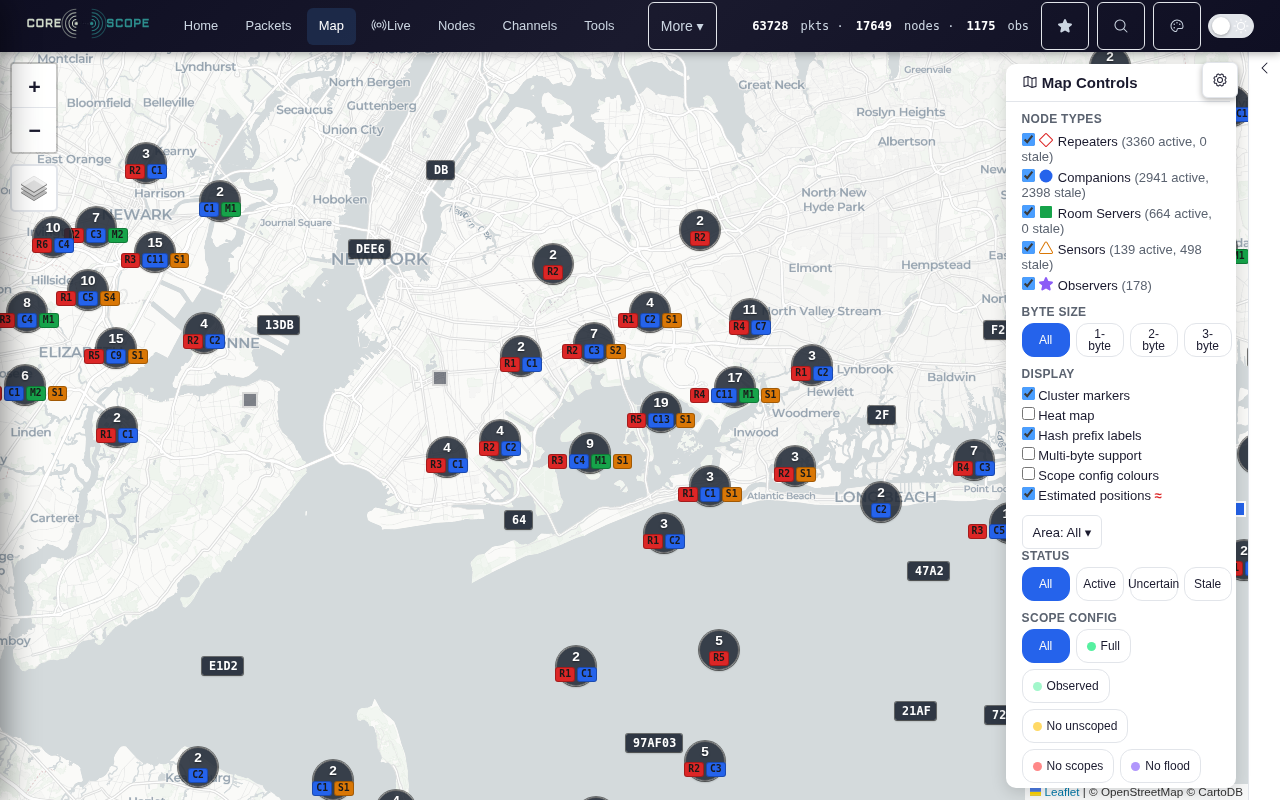
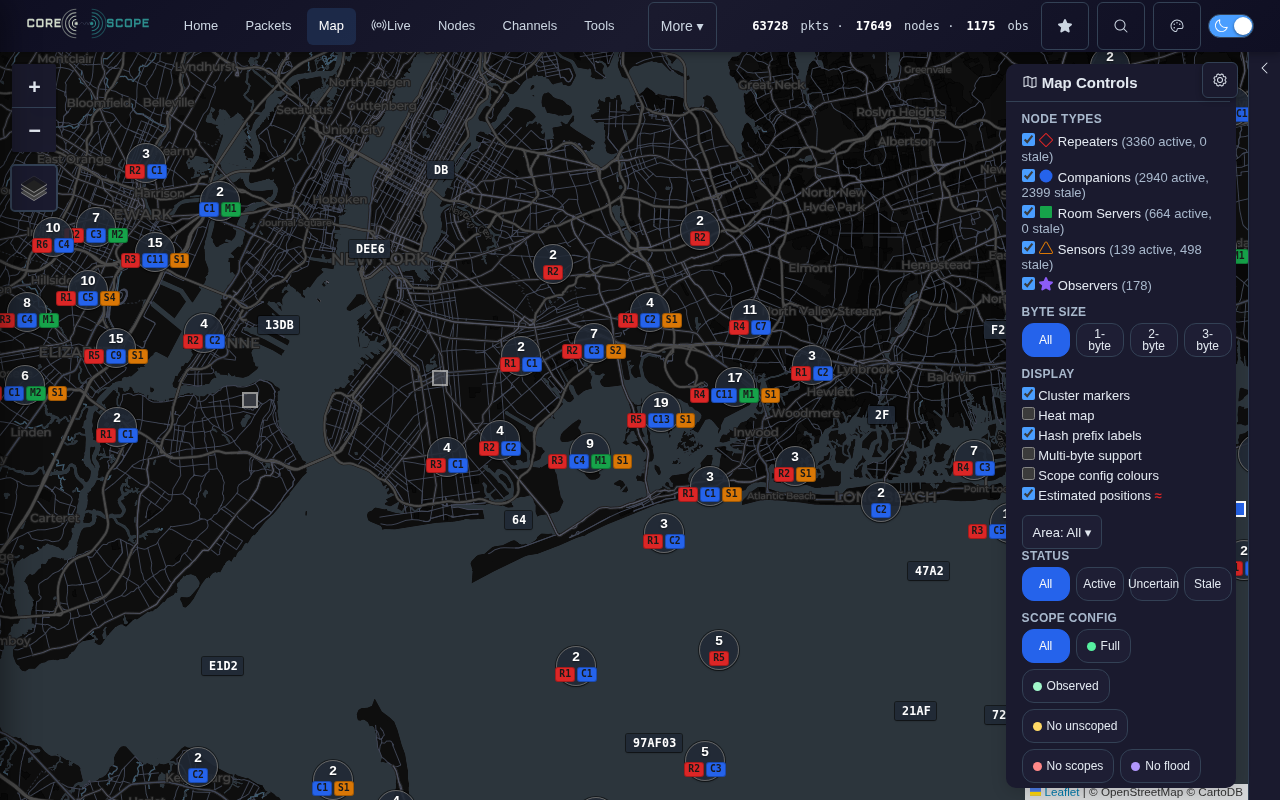
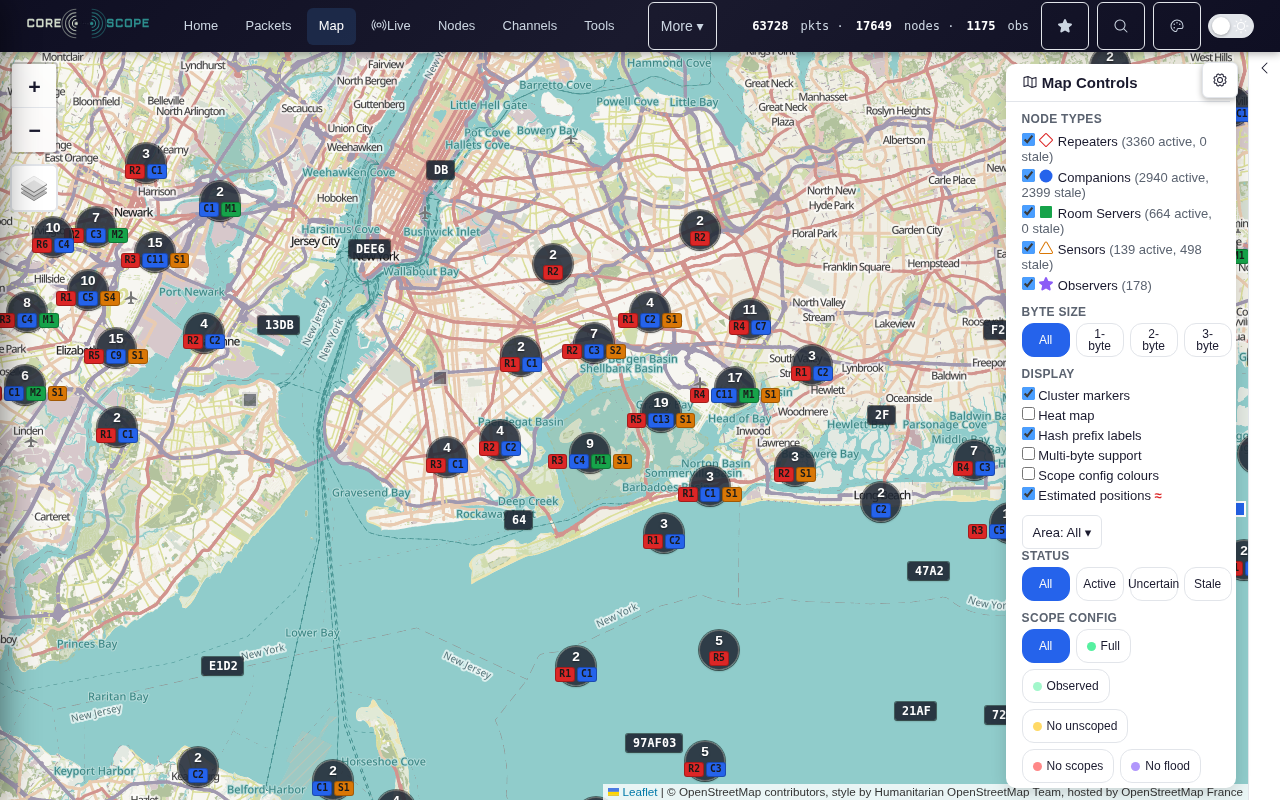
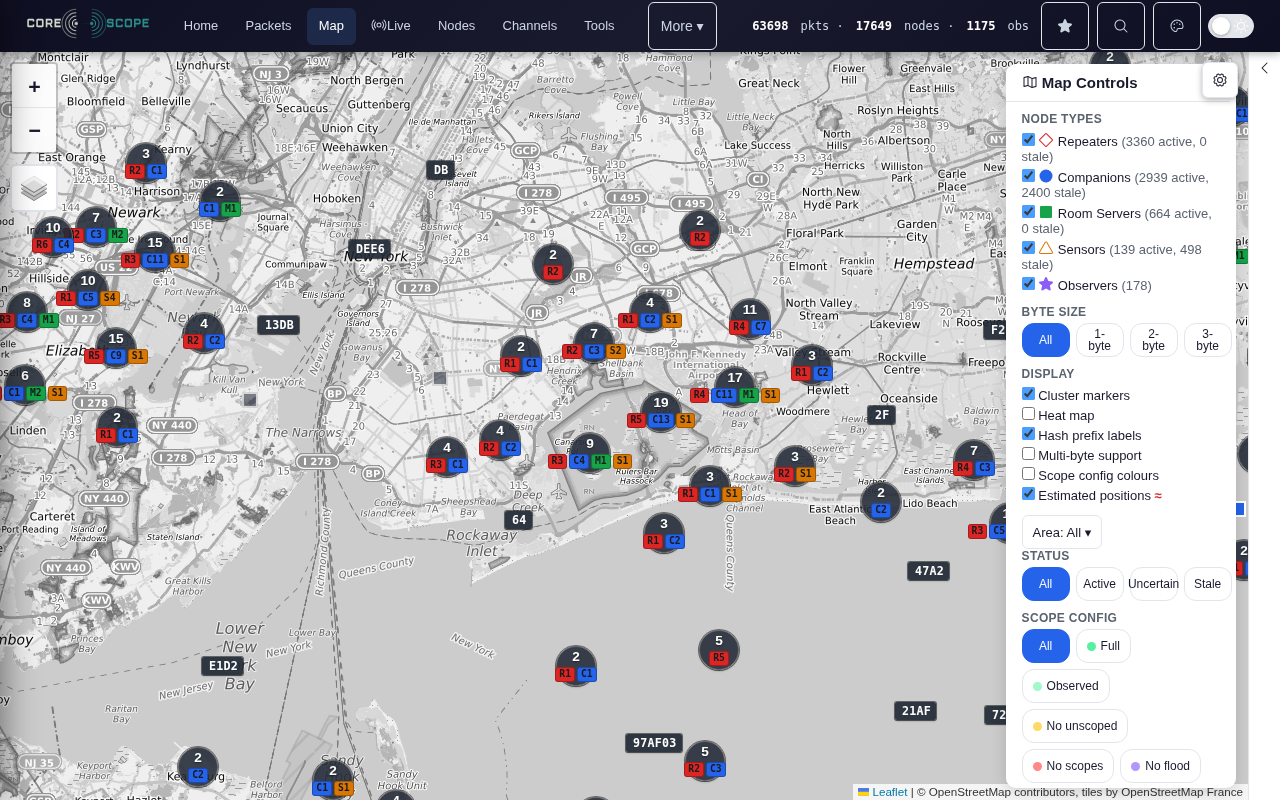
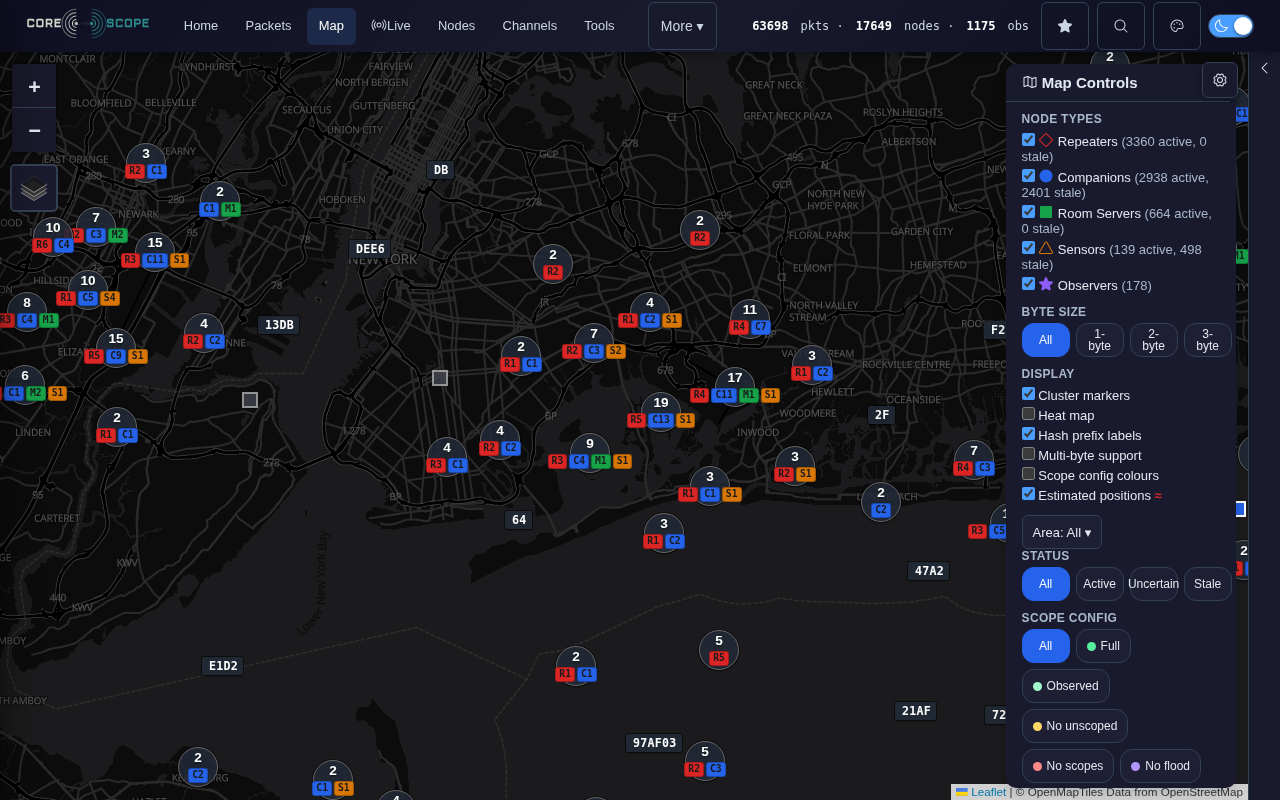
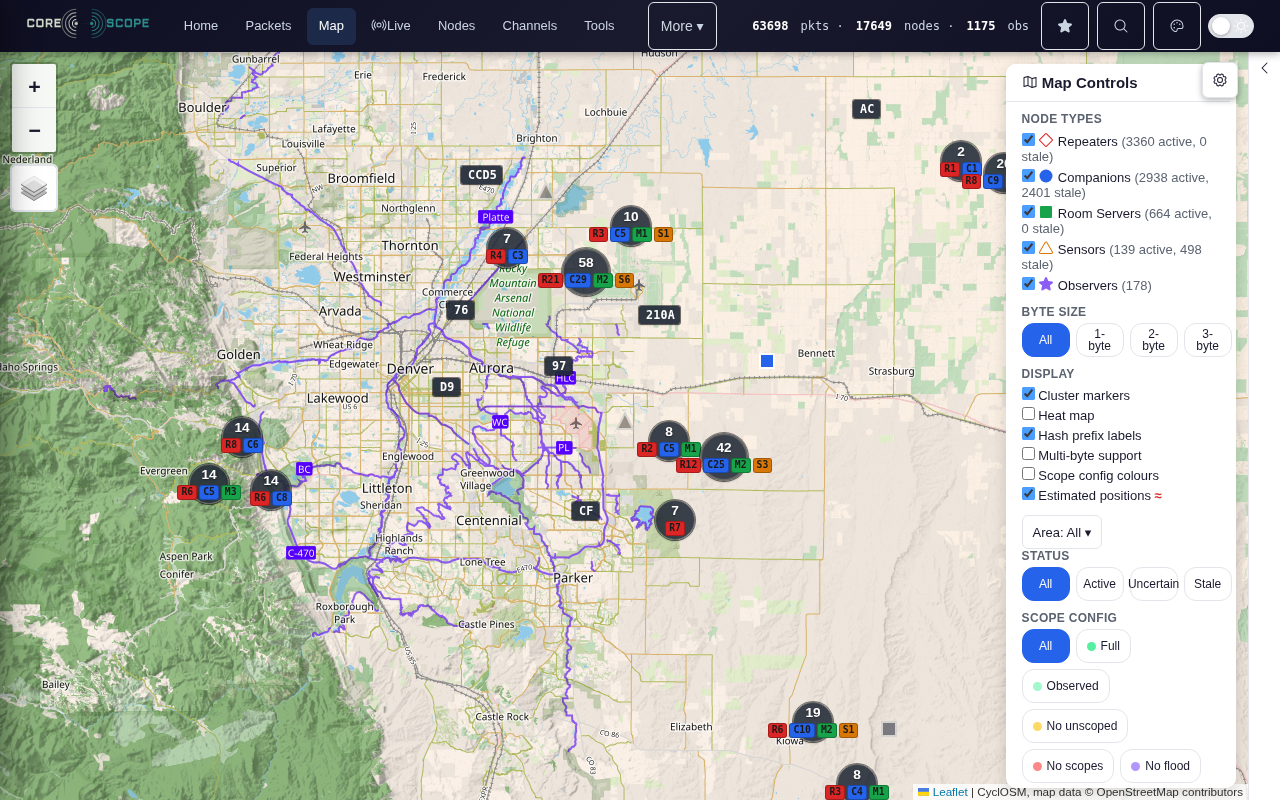
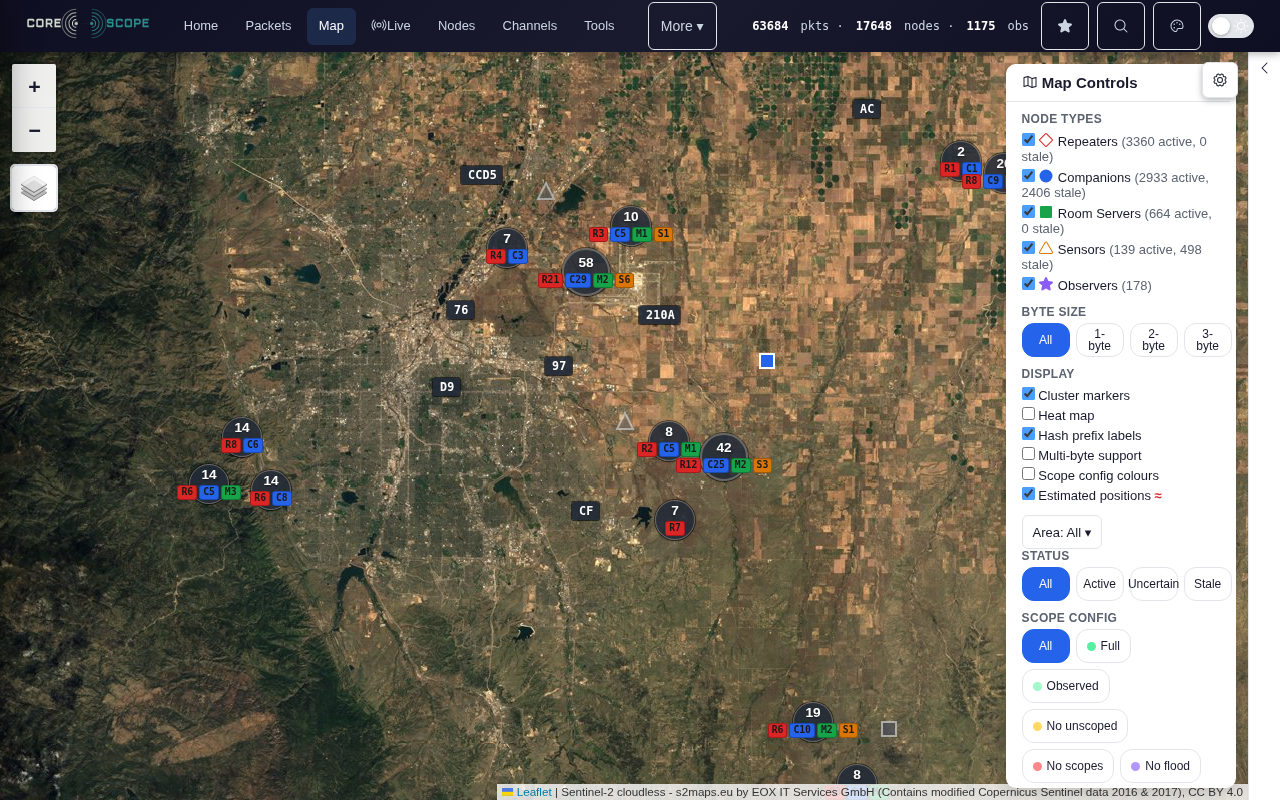
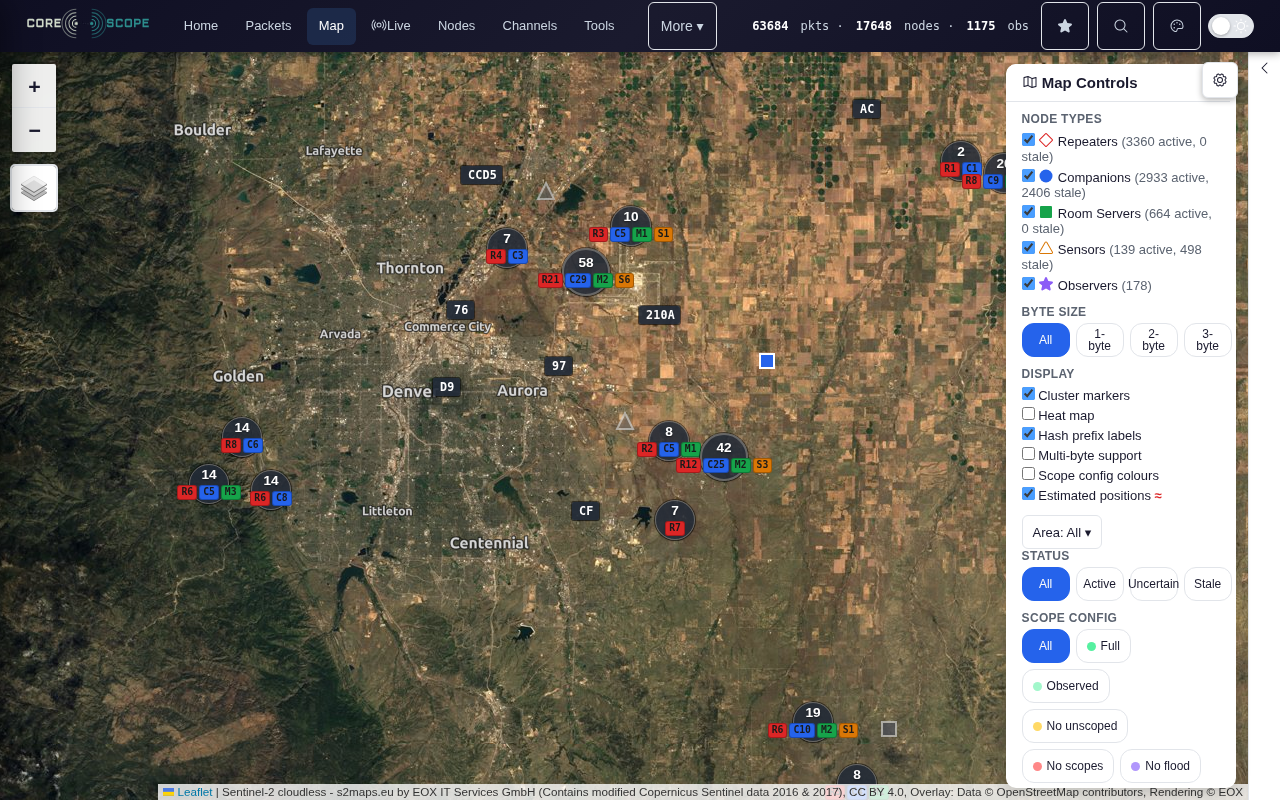
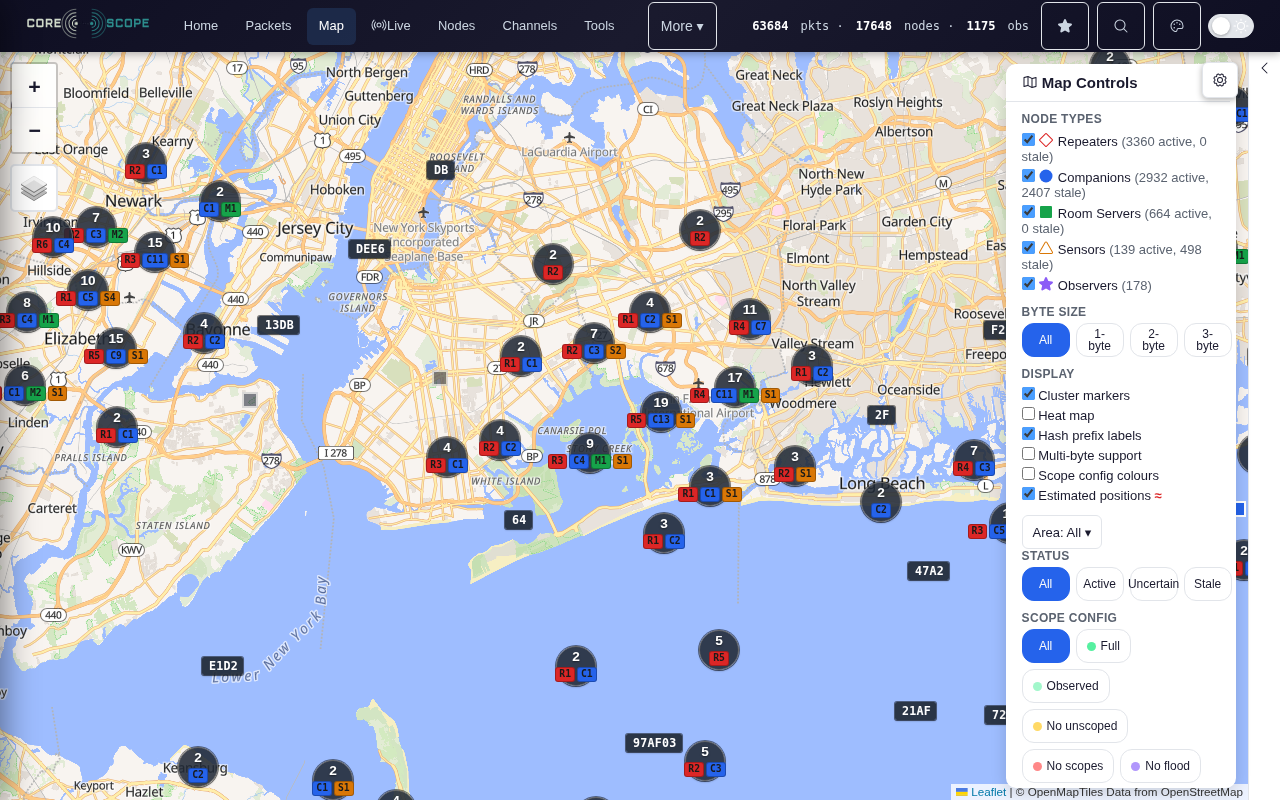
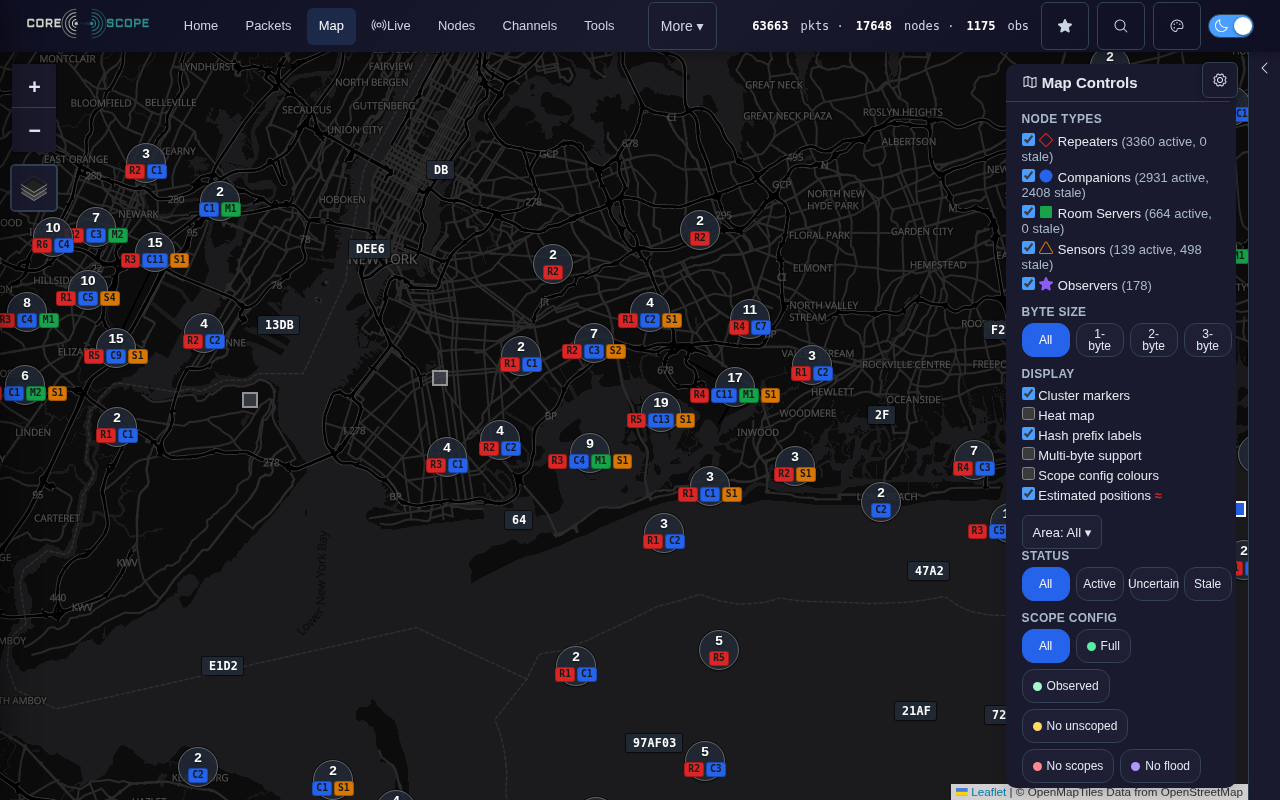
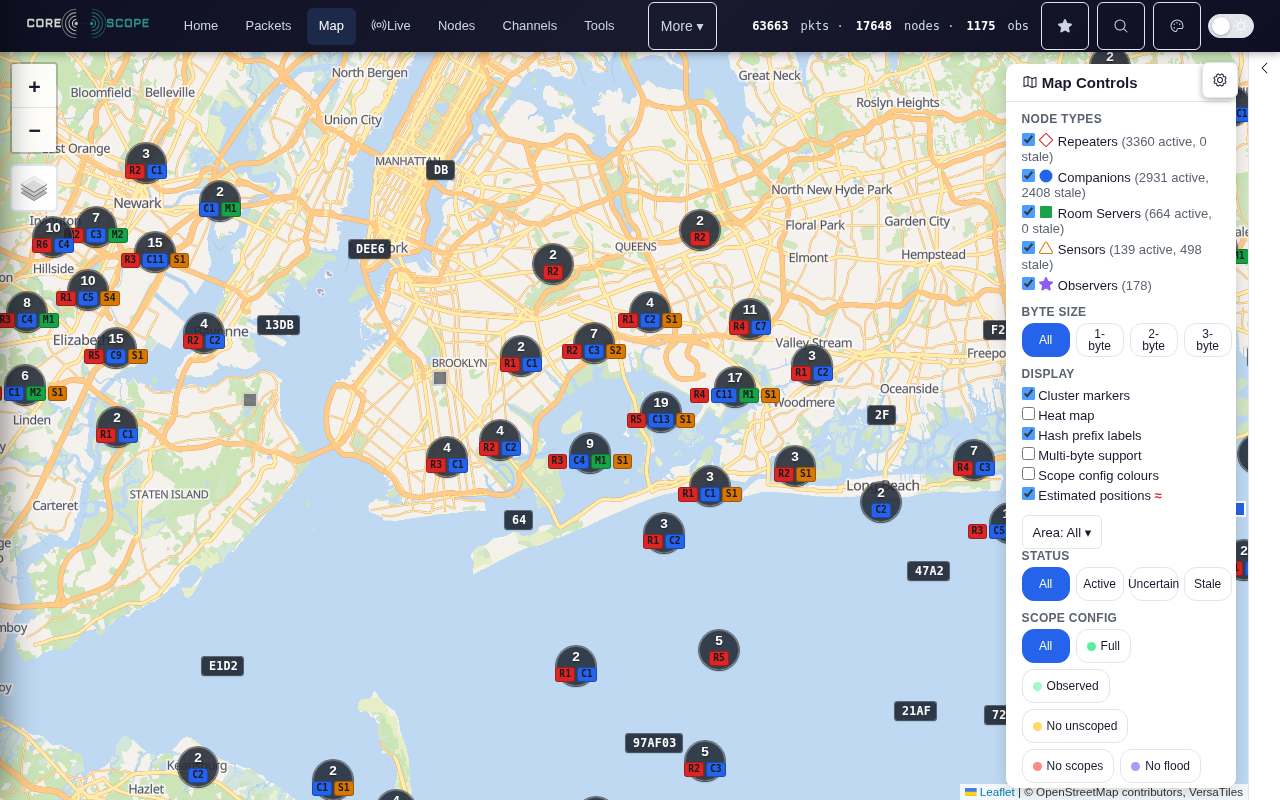
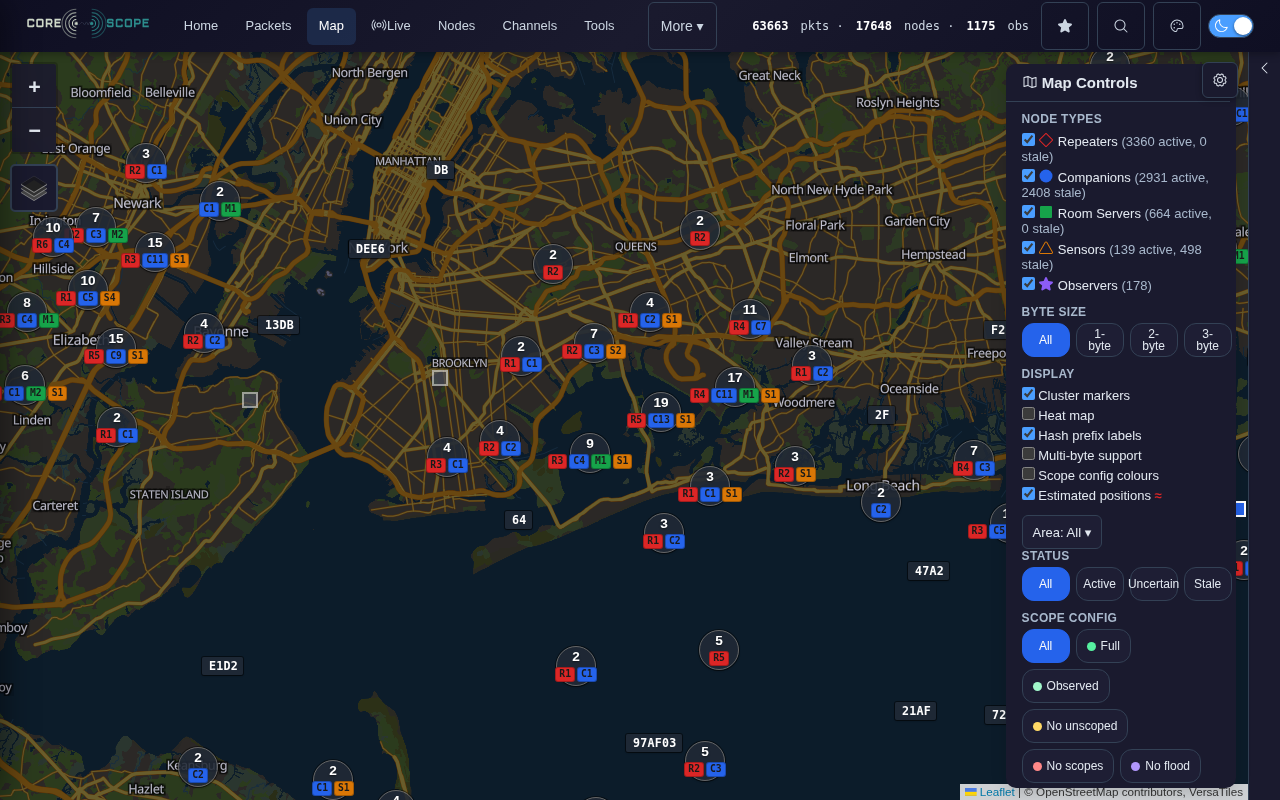
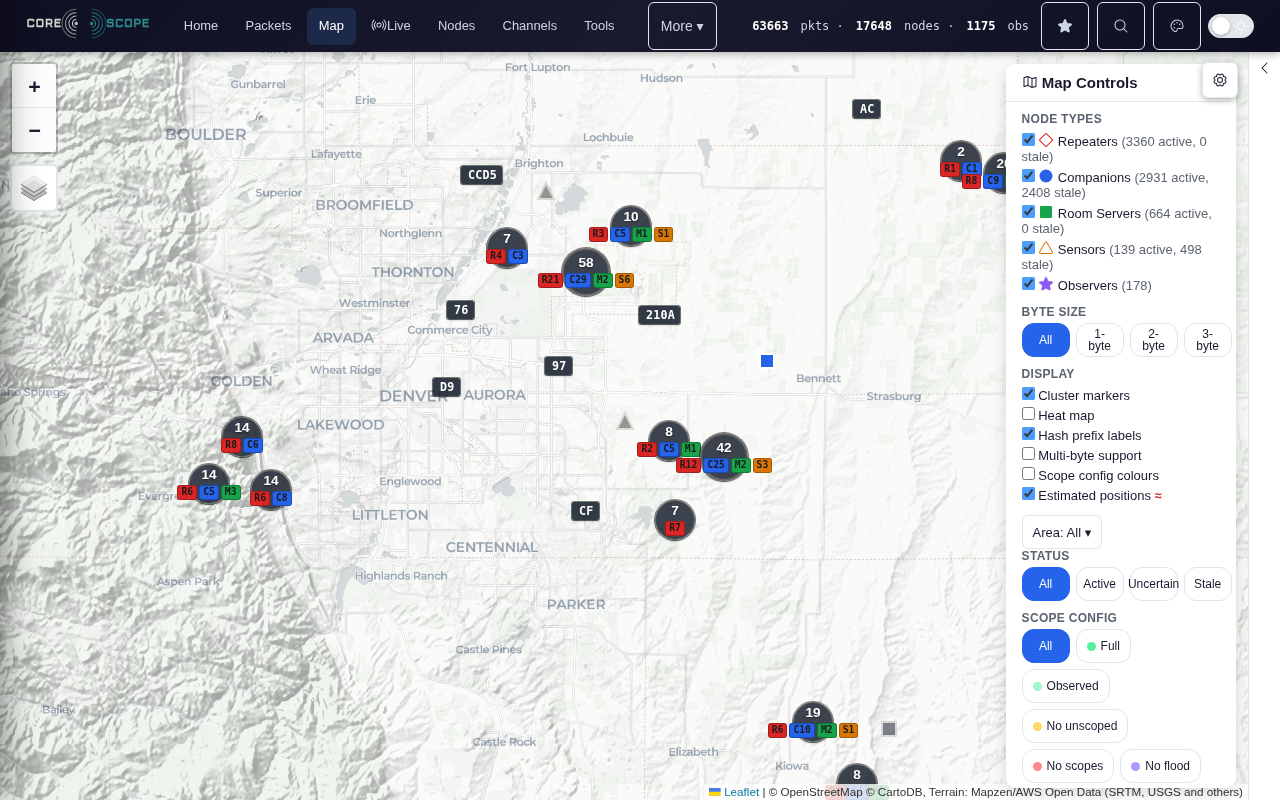
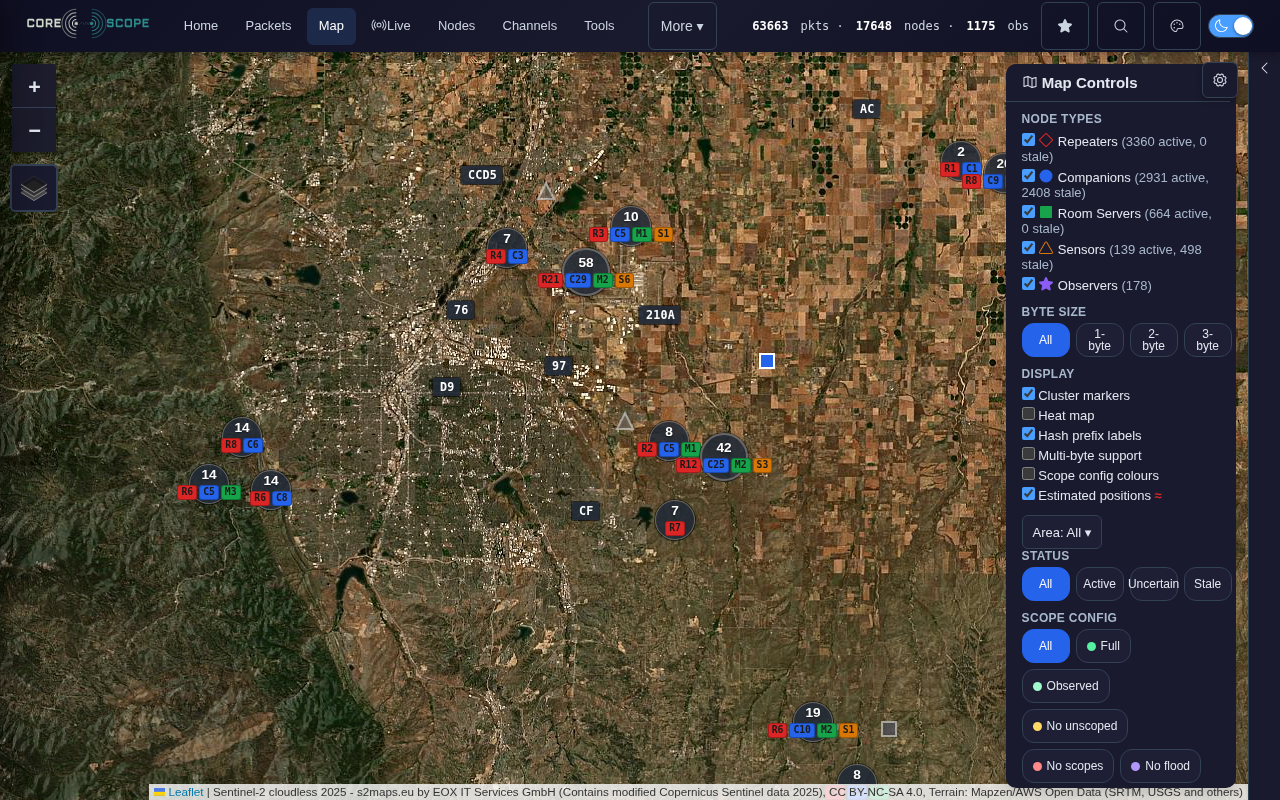
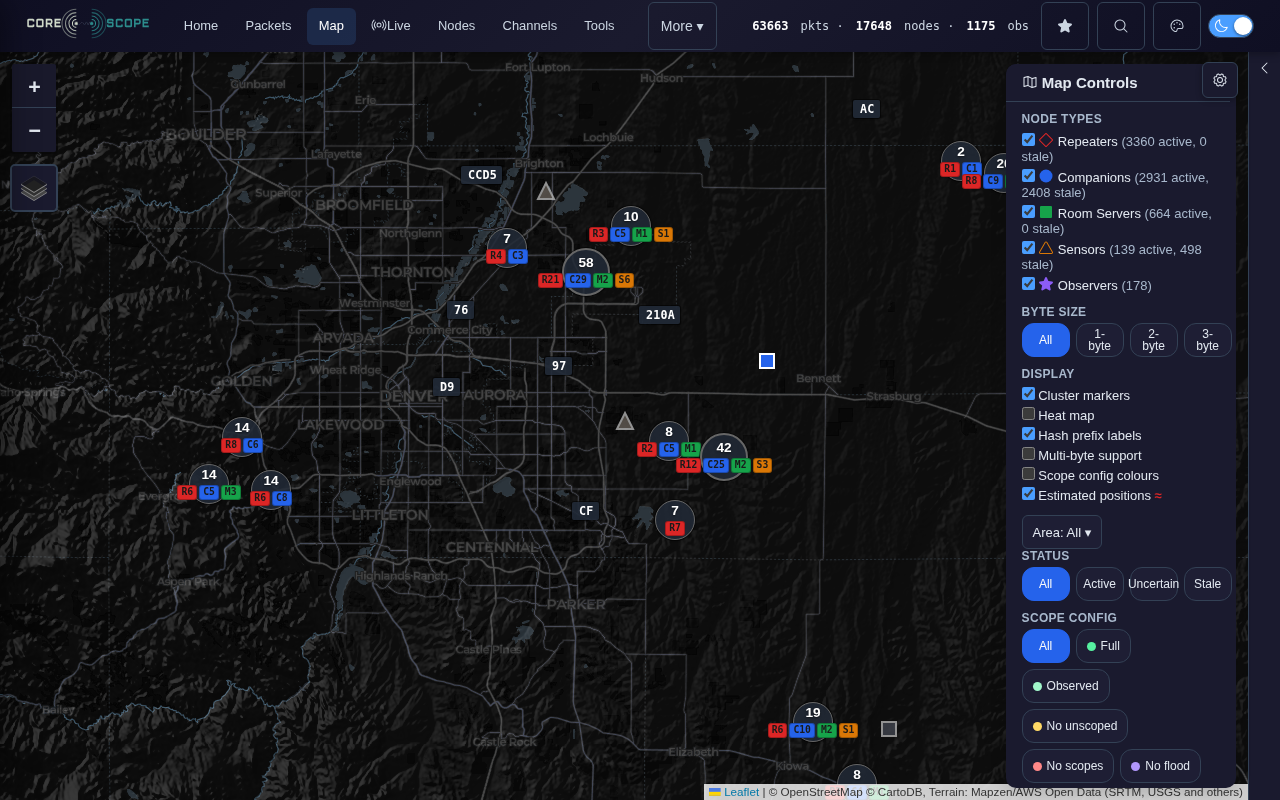
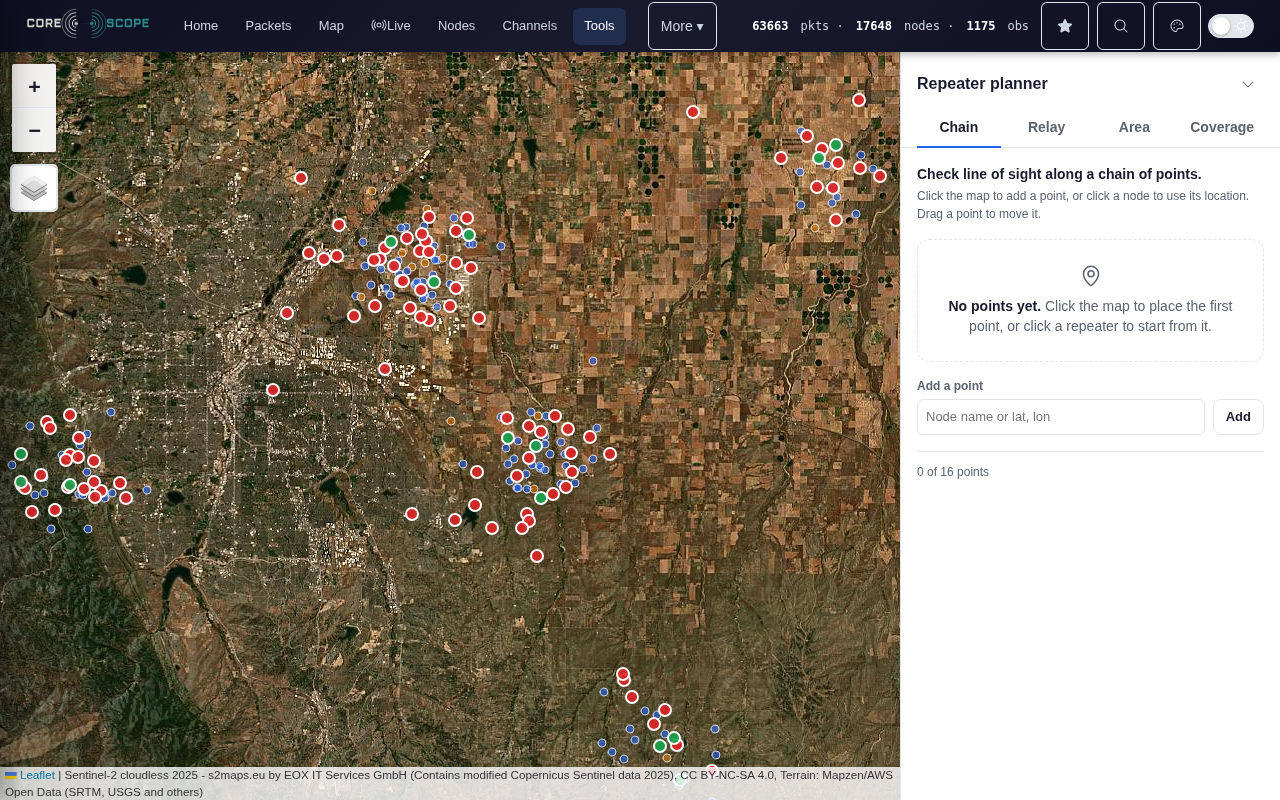
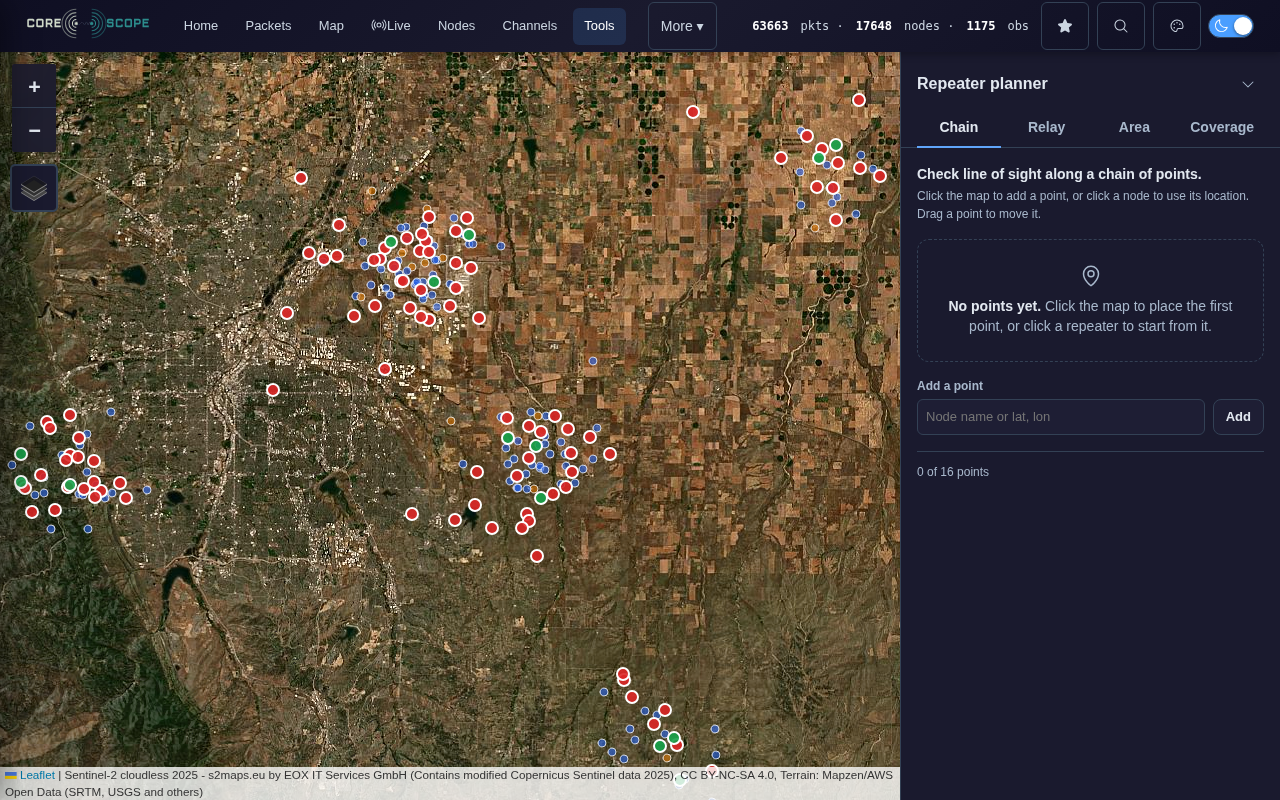
These were taken from the synthetic dataset with real tiles in a real
browser (headless Chromium, 1280×800). Click a thumbnail for the full
size. The images are hosted on a separate assets branch, so they are not
in this diff.

#### Street

| | | |
|---|---|---|
| <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/street-carto-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/street-carto-light.png"
width="260" alt="Street: Carto (default) (light)"></a><br>Carto
(default) (light) | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/street-carto-dark.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/street-carto-dark.png"
width="260" alt="Street: Carto (default) (dark)"></a><br>Carto (default)
(dark) | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/street-osmfr-hot-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/street-osmfr-hot-light.png"
width="260" alt="Street: OSM France Humanitarian (light)"></a><br>OSM
France Humanitarian (light) |

#### Gray

| | | |
|---|---|---|
| <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/gray-osmfr-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/gray-osmfr-light.png"
width="260" alt="Gray: OSM France (light)"></a><br>OSM France (light) |
<a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/gray-osmfr-dark.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/gray-osmfr-dark.png"
width="260" alt="Gray: OSM France (dark)"></a><br>OSM France (dark) | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/gray-versatiles-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/gray-versatiles-light.png"
width="260" alt="Gray: VersaTiles (light)"></a><br>VersaTiles (light) |
| <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/gray-versatiles-dark.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/gray-versatiles-dark.png"
width="260" alt="Gray: VersaTiles (dark)"></a><br>VersaTiles (dark) | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/gray-openfreemap-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/gray-openfreemap-light.png"
width="260" alt="Gray: OpenFreeMap Positron (light)"></a><br>OpenFreeMap
Positron (light) | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/gray-openfreemap-dark.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/gray-openfreemap-dark.png"
width="260" alt="Gray: OpenFreeMap Dark (dark)"></a><br>OpenFreeMap Dark
(dark) |

#### Topographic

| | | |
|---|---|---|
| <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/topo-cyclosm-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/topo-cyclosm-light.png"
width="260" alt="Topo: CyclOSM (light)"></a><br>CyclOSM (light) | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/topo-eox-terrain-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/topo-eox-terrain-light.png"
width="260" alt="Topo: EOX Terrain Light (light)"></a><br>EOX Terrain
Light (light) | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/topo-opentopomap-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/topo-opentopomap-light.png"
width="260" alt="Topo: OpenTopoMap (opt-in) (light)"></a><br>OpenTopoMap
(opt-in) (light) |

#### Satellite

| | | |
|---|---|---|
| <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/sat-s2-2025-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/sat-s2-2025-light.png"
width="260" alt="Satellite: Sentinel-2 2025 (light)"></a><br>Sentinel-2
2025 (light) | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/sat-s2-2025-labels-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/sat-s2-2025-labels-light.png"
width="260" alt="Satellite: Sentinel-2 2025 with labels
(light)"></a><br>Sentinel-2 2025 with labels (light) | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/sat-s2-2025-dark.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/sat-s2-2025-dark.png"
width="260" alt="Satellite: Sentinel-2 2025 (dark)"></a><br>Sentinel-2
2025 (dark) |
| <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/sat-s2-2025-labels-dark.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/sat-s2-2025-labels-dark.png"
width="260" alt="Satellite: Sentinel-2 2025 with labels
(dark)"></a><br>Sentinel-2 2025 with labels (dark) | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/sat-s2-2016-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/sat-s2-2016-light.png"
width="260" alt="Satellite: Sentinel-2 2016 (light)"></a><br>Sentinel-2
2016 (light) | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/sat-s2-2016-labels-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/sat-s2-2016-labels-light.png"
width="260" alt="Satellite: Sentinel-2 2016 with labels
(light)"></a><br>Sentinel-2 2016 with labels (light) |

#### Vector (MapLibre)

| | | |
|---|---|---|
| <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/vector-liberty-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/vector-liberty-light.png"
width="260" alt="Vector: OpenFreeMap Liberty
(light)"></a><br>OpenFreeMap Liberty (light) | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/vector-dark-dark.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/vector-dark-dark.png"
width="260" alt="Vector: OpenFreeMap Dark (dark)"></a><br>OpenFreeMap
Dark (dark) | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/vector-versatiles-colorful-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/vector-versatiles-colorful-light.png"
width="260" alt="Vector: VersaTiles Colorful (light)"></a><br>VersaTiles
Colorful (light) |
| <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/vector-versatiles-colorful-dark.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/vector-versatiles-colorful-dark.png"
width="260" alt="Vector: VersaTiles Colorful Dark
(dark)"></a><br>VersaTiles Colorful Dark (dark) | | |

#### Hillshade overlay

| | | |
|---|---|---|
| <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/overlay-hillshade-s2-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/overlay-hillshade-s2-light.png"
width="260" alt="Overlay: hillshade over Sentinel-2
(light)"></a><br>hillshade over Sentinel-2 (light) | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/overlay-hillshade-carto-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/overlay-hillshade-carto-light.png"
width="260" alt="Overlay: hillshade over Carto
(light)"></a><br>hillshade over Carto (light) | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/overlay-hillshade-s2-dark.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/overlay-hillshade-s2-dark.png"
width="260" alt="Overlay: hillshade over Sentinel-2
(dark)"></a><br>hillshade over Sentinel-2 (dark) |
| <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/overlay-hillshade-carto-dark.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/overlay-hillshade-carto-dark.png"
width="260" alt="Overlay: hillshade over Carto (dark)"></a><br>hillshade
over Carto (dark) | | |

#### Repeater Planner

| | |
|---|---|
| <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/planner-s2-hillshade-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/planner-s2-hillshade-light.png"
width="260" alt="Planner: Sentinel-2 + hillshade
(light)"></a><br>Sentinel-2 + hillshade (light) | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/planner-s2-hillshade-dark.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/planner-s2-hillshade-dark.png"
width="260" alt="Planner: Sentinel-2 + hillshade
(dark)"></a><br>Sentinel-2 + hillshade (dark) |

#### Layer picker

| | |
|---|---|
| <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/picker-light.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/picker-light.png"
width="260" alt="Layer picker open (light)"></a><br>Layer picker open
(light) | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/picker-dark.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/picker-dark.png"
width="260" alt="Layer picker open (dark)"></a><br>Layer picker open
(dark) |

#### Custom tile server

| | |
|---|---|
| <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/custom-map.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/custom-map.png"
width="260" alt="Custom raster provider on the map"></a><br>Custom
raster provider on the map | <a
href="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/custom-picker.png"><img
src="https://raw.githubusercontent.com/zfouts/CoreScope/35ce760b31b8365e511884fdc5e5ae873f4e28bb/map-providers-2428/thumbs/custom-picker.png"
width="260" alt="Custom raster provider in the picker"></a><br>Custom
raster provider in the picker |

## Testing

The full suite ran twice, each time on a fresh clone:

| | Pass 1 | Pass 2 |
|---|---|---|
| Commit (before rebase) | `8a56e841` | `9355169b` |
| `test-all.sh` (unit) | pass | pass |
| `npm run lint` | 0 errors (87 warnings, all pre-existing) | 0 errors
(87 warnings, all pre-existing) |
| Go `cmd/server` / `cmd/ingestor` | ok / ok | ok / ok |
| E2E, map-related files (CI fixture) | 44/44 | 44/44 + planner-on run |
| `test-e2e-playwright.js` | 149 passed, 3 skipped | 149 passed, 3
skipped |
| Race stress gate (seeds) | 101, 202: all pass | 303, 404: all pass |
| Stress with planner enabled | pass | pass (seed 505) |
| Gallery | 32/32 | 32/32 |

The rebased equivalents of the pass 1 and pass 2 commits are `fde2552c`
and `e4d5c447`.

**After the first CI run.** The two passes covered only the map-related
E2E files, and CI exposed two problems:

1. `test-issue-1206` failed 7 checks. This was the `unload` bug
described under "Fixes included".
2. The JS unit gate runs without `node_modules`, so the two new jsdom
suites crashed `test-all.sh`. Locally, jsdom was reachable from a parent
checkout, which hid this.

The second problem is fixed in `57720bf3`, following the
`domIntegration` convention in `scripts/non-unit-tests.json`.
`test-map-teardown-races.js` moved to `tests/e2e/`, and the three jsdom
zoom-limit tests split out into
`tests/e2e/test-map-vector-leaflet-zoom.js`, so 30 + 3 = 33 tests are
kept. Both run from E2E shard 2 and take a few seconds. The heavy suites
(race stress, perf, gallery) stay local-only and are not run in GitHub
Actions.

These checks ran on the fixed, rebased tree (`57720bf3`):

| Check | Result |
|---|---|
| `test-all.sh` from a copy with no `node_modules` (as CI runs it) |
pass |
| `test-test-inventory.js` | 399 suites classified |
| `npm run lint` | 0 errors |
| Go `cmd/server` / `cmd/ingestor` | ok / ok |
| `test-issue-1206-resize-observer-leak-e2e.js` | 13/13 (7 were failing)
|
| `test-e2e-playwright.js` | 149 passed, 3 skipped |
| `test-map-providers-e2e.js` / harness E2E | 17/17, 16/16 |
| `test-map-teardown-races.js` / `test-map-vector-leaflet-zoom.js` |
19/19, 3/3 |
| Race stress (3 iterations) | all scenarios pass |

The commits since pass 2 are `76c67184` (docs only), `7f8d792c` and
`57720bf3`.

**GitHub Actions on `0506fc1d` (rebased onto `master`, with the two-tab
fix): every check passed** (13 passed, 4 skipped as usual for a PR).
That covers Go build and test, all three E2E shards, the server race
detector and both image builds. The moved suites ran in shard 2
(`test-map-teardown-races.js` 19/19, `test-map-vector-leaflet-zoom.js`
3/3), and the unit gate ran `test-map-vector.js` (30/30).

**Race stress suite** (`tests/e2e/test-map-race-stress-e2e.js`). Each
gate run does 20 iterations of scenarios a to e and 50 cycles of f. The
scenarios cover:
- rapid provider switching;
- theme flips during a vector load;
- navigating away mid-load (including a 15 s MapLibre timeout);
- repeated map-page navigation with heap checks;
- overlay toggles;
- cross-page picker persistence.

Results for each run:
- Listener counts stay flat: at most 3 `mc-tile-provider-changed`
listeners and 5 `storage` listeners.
- At most one live WebGL context at a time.
- Heap growth in the second half of scenario d was 0.25 to 0.45 MB
across the four gate runs.
- Upstream `master` grows about 0.39 MB per map navigation loop in the
same scenario; this branch levels off.

## Maintainer review (addressed)

1. **Licence default.** All five new groups (`eox`, `osmfr`,
`openfreemap`, `versatiles`, `hillshade`) are opt-in: off unless
`enabled: true` (`"true"`, `1` or `{}` don't count). With an untouched
config the picker lists the same 6 base maps as before. Docs,
`config.example.json` (now `enabled: false` for each) and the changelog
say so, and each group's terms are listed before you turn it on.
2. **Saved pick.** The on-map picker now saves the pick (option 1 of
your two), as the docs promised. Behaviour, and what an other-theme pick
does:
- Every picker opens on the pinned map, on any page and after a reload,
until **Auto** is picked. A pin is shown whatever the theme, as an
explicit pick already was.
- Maps without a picker show it when it fits the current theme (`type`
is the theme or `any`), otherwise the theme's map. So a light pin isn't
drawn on a dark node map; satellite always is.
- A stored pin whose group is turned off reads as Auto, and comes back
if the group is turned on again; only picking Auto clears it.
- On a map with a picker, Auto always means the theme's map: the pin is
only the explicit layer, never loaded into the hidden Auto layer. A
choice in the customizer, and Reset All, clear the pin. A failed write
(quota full) never brings back an older stored pin.
- E2E `7a` to `7c` in `test-map-providers-e2e.js`: pick, reload, the
radio and tiles are the pick, the node detail map draws it, and a light
pin in dark is kept but not drawn. Auto clears the key; junk in it gives
Auto; an untouched config lists none of the new groups. 7a and 7b fail
with the save line removed. Unit tests are in `test-map-tile-pin.js`
(21).
3. **CI.** `test-map-providers-e2e.js` (24 checks, including `4b`, the
two-tab regression check) and `test-map-providers-harness-e2e.js` (16)
now run in E2E shard 3 against the fixture server: every tile host is
stubbed.

Non-blocking:
- `getTileUrl()` now returns the raster fallback for a vector pick
(`MC_rasterTileUrl`). There's a test in `test-tile-resolver.js` that
fails on the old code.
- The `map-vector.js` header and the binding's vendor README list the
Leaflet and binding internals to recheck on an upgrade.
- `docs/deployment.md` says SRI makes a JS-rewriting proxy drop vector
maps to raster, so serve `public/vendor/` unmodified.
- `scripts/map-perf/README.md` says where `SEED_DB` and `SHIFT_SH` come
from.
- The maps with `attributionControl: false` are left as they are. That
predates this PR, and with every new group opt-in, an upgrade adds no
uncredited imagery. Follow-up for all of them: #2441.
- The OpenFreeMap credit line is `OpenFreeMap © OpenMapTiles Data from
OpenStreetMap` (`2424f3c3`), the line OpenFreeMap gives for clients that
don't add it automatically.

Verified after these changes:
- `test-all.sh` and lint pass, with 0 errors.
- Both provider E2E suites pass: 24/24 and 16/16.
- Race stress, seed 979: scenarios a, b, d and e pass. c (15/15) and f
(37/37) pass after updating their model of the pick: they expected Auto
after a return, which was the old unsaved behaviour.
- The stress suite now enables the five groups itself, so it keeps
exercising them.

## Performance

A/B test: `master` against this branch on the large synthetic dataset,
with 9 runs per scenario and stubbed tiles (see Test data;
`scripts/map-perf/`). The full HTML report is not attached; ask if you
want it.

- **No budget failures** in either pass. The `raster-no-maplibre` budget
holds: no raster scenario loads MapLibre.
- **DOMContentLoaded is unchanged on every page**, even with the two new
scripts (`map-hillshade.js` and `map-vector.js`, about 635 lines in all;
MapLibre itself loads only on demand).
- **Switching providers 50 times (raster only), median ms per switch:**
  - dark: 146 → 108.5;
  - light: 208 → 208.5.
  - Heap growth during the run: 0.3 to 0.4% on both sides.
- **Flagged and checked:**
- Live and Analytics `loadEventMs` are flagged in some runs. This metric
has two modes on **both** branches: `load` fires either before Leaflet
adds its first tile `<img>`s (about 150 ms) or after they finish (about
400 ms). A direct probe of `master` alone gave 428, 404 and 124 ms. On
these scenarios, map creation, first tile, all tiles, first marker and
wall time are within a few ms on both sides.
- Carto and Positron `allTilesSinceMapMs` are 4 to 6 ms slower, just
above `master`'s p95. Tiles are stubbed locally, so this is not network
noise. The cause is not isolated. Both providers now go through the
shared layer builder, and on the same scenarios first tile, all tiles
and wall time are within 10 ms of `master` (Carto Voyager +2 to +3 ms;
Positron Dark +6 to +9 ms).
- The Analytics map shows one long task of about 50 ms against a
`master` median of 0, but `master`'s p95 is 52 to 84 ms. This is
disclosed in case it shows up for you.
- Other desktop apps were running during the perf runs, so expect some
noise.

## Commits

1. `c6bf12ed` feat(map): tile provider registry with custom servers,
gray, topo and satellite maps, and overlays
2. `9237230b` feat(map): client-side hillshade overlay
3. `781e41b4` feat(map): vector basemaps via vendored MapLibre GL 5.24.0
4. `dae36d2e` refactor(map): every map surface uses the shared basemap
builder
5. `3d4afcdc` fix(map): teardown races and listener leaks when leaving
map pages
6. `b798b2fe` test(server): pin map.tiles passthrough in
/api/config/client
7. `171b1bc4` test(map): E2E, race stress suite, perf harness and
screenshot gallery
8. `61f73875` docs(map): providers, custom tile servers, overlays and
self-hosting
9. `135a9b12` test(map): gallery shows opt-in OpenTopoMap and retries
slow tile servers
10. `3833572b` test(map): harness waits for vector basemaps; stress
suite fixes from test pass 1
11. `3e543cad` test(map-perf): redact tile-URL credentials; compare
switch50 like with like
12. `d5006111` docs(map): user guide for map styles, overlays and
map.tiles
13. `90ee1d5d` fix(map): MC_safeRemoveMap lets unload listeners run
before dropping them
14. `5fc57b5c` test(map): run the jsdom map suites in the E2E job, not
the unit gate
15. `bd36b634` fix(map): another tab's overlay pick that lands mid-click
is no longer removed
16. `38df65d2` fix(map): new tile groups are opt-in; a map picked in the
picker is saved
17. `eafbcac9` ci(e2e): run the map provider E2E suites in shard 3
18. `65b223ec` fix(map): getTileUrl() never returns a vector style url;
review notes
19. `f3402c5d` test(map): race stress enables the opt-in groups and
expects the saved pick
20. `e92b8631` fix(map): Auto on a picker map ignores the saved pick;
customizer clears it

🤖 Generated with [Claude Code](https://claude.com/claude-code)

---------

Co-authored-by: Claude Opus 5.5 <noreply@anthropic.com>


154 lines
7.0 KiB
JavaScript
154 lines
7.0 KiB
JavaScript
/* test-map-vector-leaflet-zoom.js — vector basemap zoom limits (#2428).
|
|
*
|
|
* Runs the real public/map-vector.js against the real vendored Leaflet and
|
|
* markercluster in jsdom: the vector group sets the map's min/max zoom on
|
|
* add, before MapLibre arrives, while GL is shown and after a raster
|
|
* fallback, and leaves no limit behind when removed.
|
|
*
|
|
* Needs jsdom, so it is a domIntegration suite (scripts/non-unit-tests.json)
|
|
* run from the E2E job, not test-all.sh. No server or browser needed.
|
|
* The rest of map-vector.js is covered by tests/unit/test-map-vector.js.
|
|
*
|
|
* Runs via: node tests/e2e/test-map-vector-leaflet-zoom.js
|
|
*/
|
|
'use strict';
|
|
const fs = require('fs');
|
|
const path = require('path');
|
|
const assert = require('assert');
|
|
|
|
const SRC = fs.readFileSync(path.join(__dirname, '..', '..', 'public', 'map-vector.js'), 'utf8');
|
|
const ATTR = '© OpenFreeMap © OpenMapTiles';
|
|
const STYLE = 'https://tiles.openfreemap.org/styles/liberty';
|
|
|
|
let passed = 0, failed = 0;
|
|
const queue = [];
|
|
function test(name, fn) { queue.push([name, fn]); }
|
|
const flush = () => new Promise((r) => setImmediate(r));
|
|
|
|
function makeEvented(obj) {
|
|
const handlers = {};
|
|
obj.on = function (type, fn) { (handlers[type] = handlers[type] || []).push(fn); return obj; };
|
|
obj.once = function (type, fn) {
|
|
const w = function (e) { obj.off(type, w); fn(e); };
|
|
return obj.on(type, w);
|
|
};
|
|
obj.off = function (type, fn) { handlers[type] = (handlers[type] || []).filter((h) => h !== fn); return obj; };
|
|
obj.fire = function (type, e) { (handlers[type] || []).slice().forEach((h) => h(e || {})); return obj; };
|
|
return obj;
|
|
}
|
|
|
|
// ── zoom limits, against the real vendored Leaflet (jsdom) ──────────────
|
|
// Leaflet registers a layer's min/maxZoom with the map only for GridLayers;
|
|
// markercluster's onAdd throws "Map has no maxZoom specified" without one.
|
|
const { JSDOM } = require('jsdom');
|
|
const VENDOR_DIR = path.join(__dirname, '..', '..', 'public', 'vendor');
|
|
function makeLeafletSandbox() {
|
|
const dom = new JSDOM('<!doctype html><html><head></head><body><div id="m" style="width:400px;height:300px"></div></body></html>',
|
|
{ runScripts: 'outside-only', url: 'https://example.org/sub/' });
|
|
const w = dom.window;
|
|
w.eval(fs.readFileSync(path.join(VENDOR_DIR, 'leaflet-1.9.4', 'leaflet.js'), 'utf8'));
|
|
w.eval(fs.readFileSync(path.join(VENDOR_DIR, 'leaflet.markercluster.js'), 'utf8'));
|
|
w.HTMLCanvasElement.prototype.getContext = () => ({ getExtension: () => null });
|
|
w.console.warn = () => {};
|
|
// Fake timers for map-vector.js only; Leaflet keeps the real ones.
|
|
let now = 0, timers = [];
|
|
w.__st = (fn, ms) => { const t = { fn, at: now + ms, id: timers.length + 1 }; timers.push(t); return t.id; };
|
|
w.__ct = (id) => { timers = timers.filter((t) => t.id !== id); };
|
|
function advance(ms) { now += ms; const due = timers.filter((t) => t.at <= now); timers = timers.filter((t) => t.at > now); due.forEach((t) => t.fn()); }
|
|
w.eval('(function (setTimeout, clearTimeout) {\n' + SRC + '\n})(window.__st, window.__ct);');
|
|
const L = w.L;
|
|
// Mirrors leaflet-maplibre-gl's shape: a plain L.Layer, not a GridLayer.
|
|
const FakeGL = L.Layer.extend({
|
|
onAdd() { this._glMap = makeEvented({ remove() {} }); },
|
|
onRemove() { this._glMap = null; },
|
|
getMaplibreMap() { return this._glMap; },
|
|
});
|
|
function loadLibrary() {
|
|
const tags = Array.from(w.document.head.querySelectorAll('script[data-mc-maplibre]'));
|
|
w.maplibregl = { setWorkerUrl() {} };
|
|
tags[0].onload();
|
|
L.maplibreGL = (o) => new FakeGL(o);
|
|
tags[1].onload();
|
|
}
|
|
function build(desc) {
|
|
return w.MC_buildVectorLayer(Object.assign({ url: STYLE, attribution: ATTR, maxZoom: 19 }, desc),
|
|
{ fallback: () => L.tileLayer('https://t.example.org/{z}/{x}/{y}.png', { maxZoom: (desc && desc.maxZoom) || 19 }) });
|
|
}
|
|
const newMap = () => { const el = w.document.createElement('div'); w.document.body.appendChild(el); return L.map(el); };
|
|
return { w, L, advance, loadLibrary, build, newMap };
|
|
}
|
|
|
|
test('Leaflet: a vector group sets the map zoom limit before MapLibre arrives; markers can be added at once', async () => {
|
|
const s = makeLeafletSandbox();
|
|
const map = s.newMap().setView([0, 0], 5);
|
|
assert.strictEqual(map.getMaxZoom(), Infinity, 'no limit without a basemap');
|
|
const g = s.build({ maxZoom: 17, minZoom: 2 });
|
|
map.addLayer(g);
|
|
assert.strictEqual(map.getMaxZoom(), 17, 'limit set synchronously on add');
|
|
assert.strictEqual(map.getMinZoom(), 2);
|
|
assert.doesNotThrow(() => s.L.markerClusterGroup().addTo(map), 'markercluster finds a maxZoom');
|
|
map.removeLayer(g);
|
|
assert.strictEqual(map.getMaxZoom(), Infinity, 'no lingering limit');
|
|
assert.strictEqual(map.getMinZoom(), 0);
|
|
});
|
|
|
|
test('Leaflet: the limit holds while GL is shown and after a raster fallback; removed symmetrically', async () => {
|
|
const s = makeLeafletSandbox();
|
|
const map = s.newMap().setView([0, 0], 5);
|
|
const g = s.build({ maxZoom: 18 });
|
|
map.addLayer(g);
|
|
s.loadLibrary(); await flush();
|
|
assert.strictEqual(g.getLayers().length, 1, 'GL mounted');
|
|
assert.ok(g.getLayers()[0].getMaplibreMap(), 'GL mounted');
|
|
assert.strictEqual(map.getMaxZoom(), 18, 'GL shown');
|
|
map.removeLayer(g);
|
|
assert.strictEqual(map.getMaxZoom(), Infinity);
|
|
map.addLayer(g);
|
|
assert.strictEqual(map.getMaxZoom(), 18, 're-added');
|
|
map.removeLayer(g);
|
|
|
|
const g2 = s.build({ maxZoom: 18 });
|
|
map.addLayer(g2);
|
|
s.advance(15000);
|
|
assert.strictEqual(g2.mcFallbackReason, 'load-timeout');
|
|
assert.strictEqual(map.getMaxZoom(), 18, 'after the raster fallback');
|
|
map.removeLayer(g2);
|
|
assert.strictEqual(map.getMaxZoom(), Infinity, 'fallback and group both unregistered');
|
|
});
|
|
|
|
test('Leaflet: switching raster <-> vector moves the limit; a group added and removed before load leaves none', () => {
|
|
const s = makeLeafletSandbox();
|
|
const map = s.newMap();
|
|
const early = s.build({ maxZoom: 12 });
|
|
map.addLayer(early);
|
|
map.removeLayer(early); // before setView: Leaflet skips onRemove
|
|
map.setView([0, 0], 5);
|
|
assert.strictEqual(map.getMaxZoom(), Infinity, 'pre-load add/remove leaves no limit');
|
|
const raster = s.L.tileLayer('https://t.example.org/{z}/{x}/{y}.png', { maxZoom: 16 }).addTo(map);
|
|
assert.strictEqual(map.getMaxZoom(), 16);
|
|
map.removeLayer(raster);
|
|
const g = s.build({ maxZoom: 19 });
|
|
map.addLayer(g);
|
|
assert.strictEqual(map.getMaxZoom(), 19, 'raster -> vector');
|
|
map.removeLayer(g);
|
|
raster.addTo(map);
|
|
assert.strictEqual(map.getMaxZoom(), 16, 'vector -> raster');
|
|
|
|
const map2 = s.newMap();
|
|
const g3 = s.build({ maxZoom: 14 });
|
|
map2.addLayer(g3); // before load: limit already set, kept through load
|
|
assert.strictEqual(map2.getMaxZoom(), 14);
|
|
map2.setView([0, 0], 5);
|
|
assert.strictEqual(map2.getMaxZoom(), 14);
|
|
assert.doesNotThrow(() => s.L.markerClusterGroup().addTo(map2));
|
|
});
|
|
|
|
(async () => {
|
|
for (const [name, fn] of queue) {
|
|
try { await fn(); passed++; console.log(' ✅ ' + name); }
|
|
catch (e) { failed++; console.log(' ❌ ' + name + ': ' + e.message); }
|
|
}
|
|
console.log(`\nmap-vector-leaflet-zoom: ${passed} passed, ${failed} failed`);
|
|
process.exit(failed > 0 ? 1 : 0);
|
|
})();
|